iris
Aim to accelerate the learning loop from field data to mission-specific vision models.
Demo mode
What I’m building
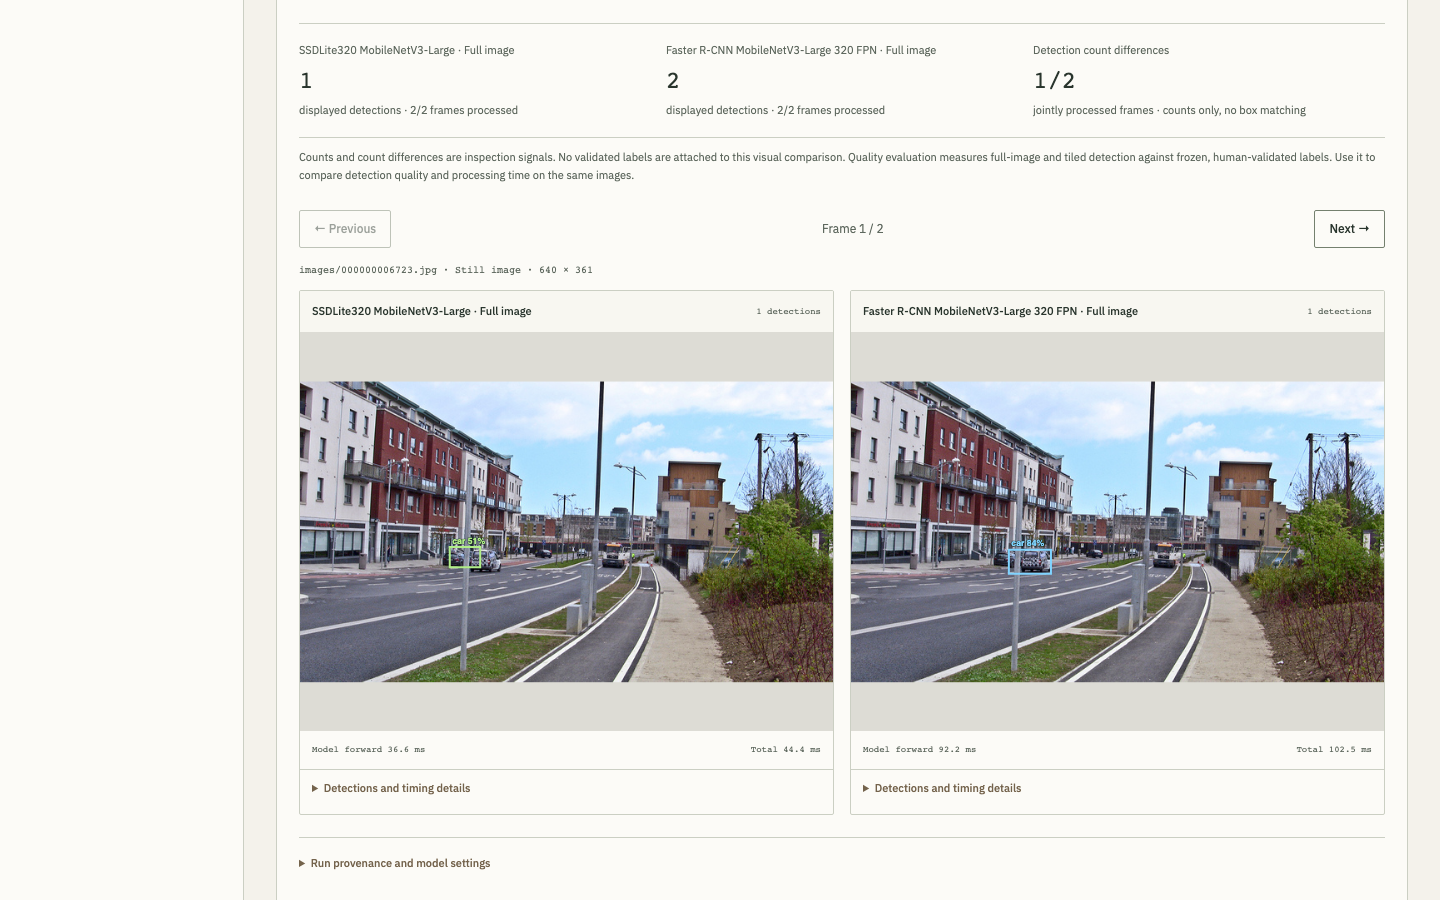
I’m building iris to make improving computer vision models faster and easier. The idea is to bring your own images and videos, train models adapted to your needs, compare them with previous versions and easily choose which one to deploy. For example, you come back from a drone flight with new recordings. You give them to iris, train a new model and compare it with the old one before trying it on the next flight. You can keep different models for different missions and pick the one you need. I want to remove as much friction as possible from that learning loop. Collect new data, train, compare, deploy and repeat.
Where it is now
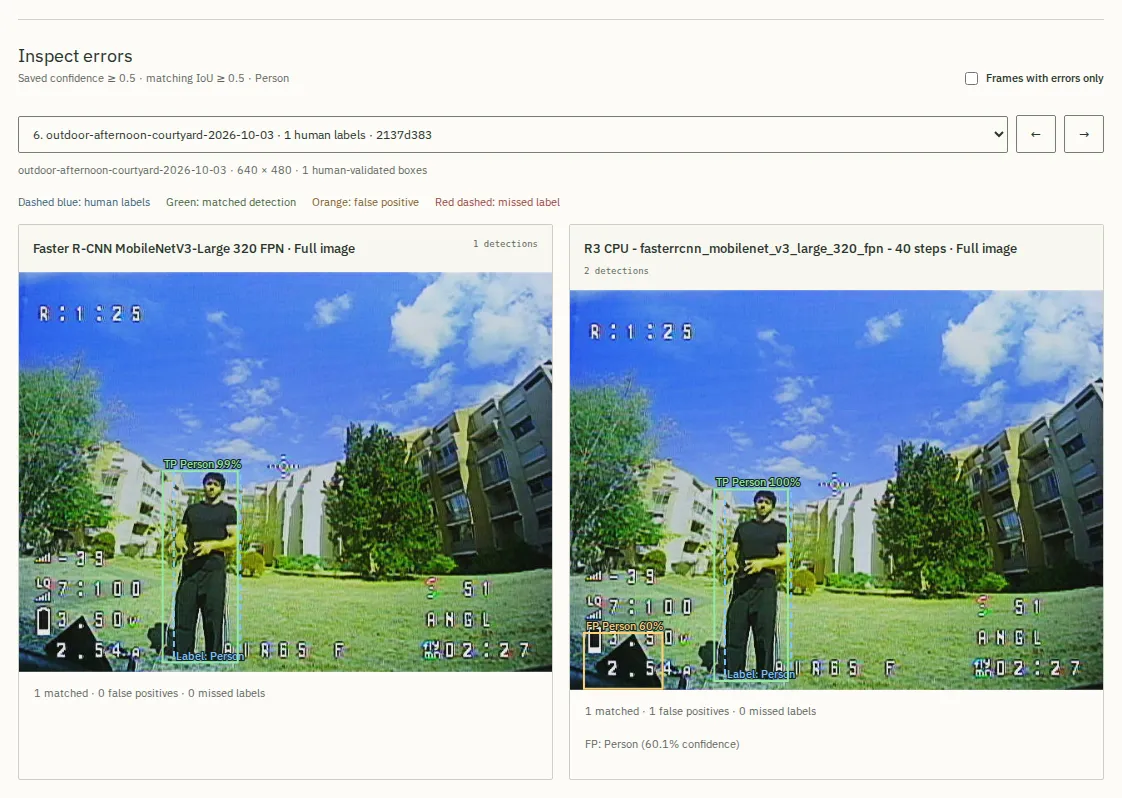
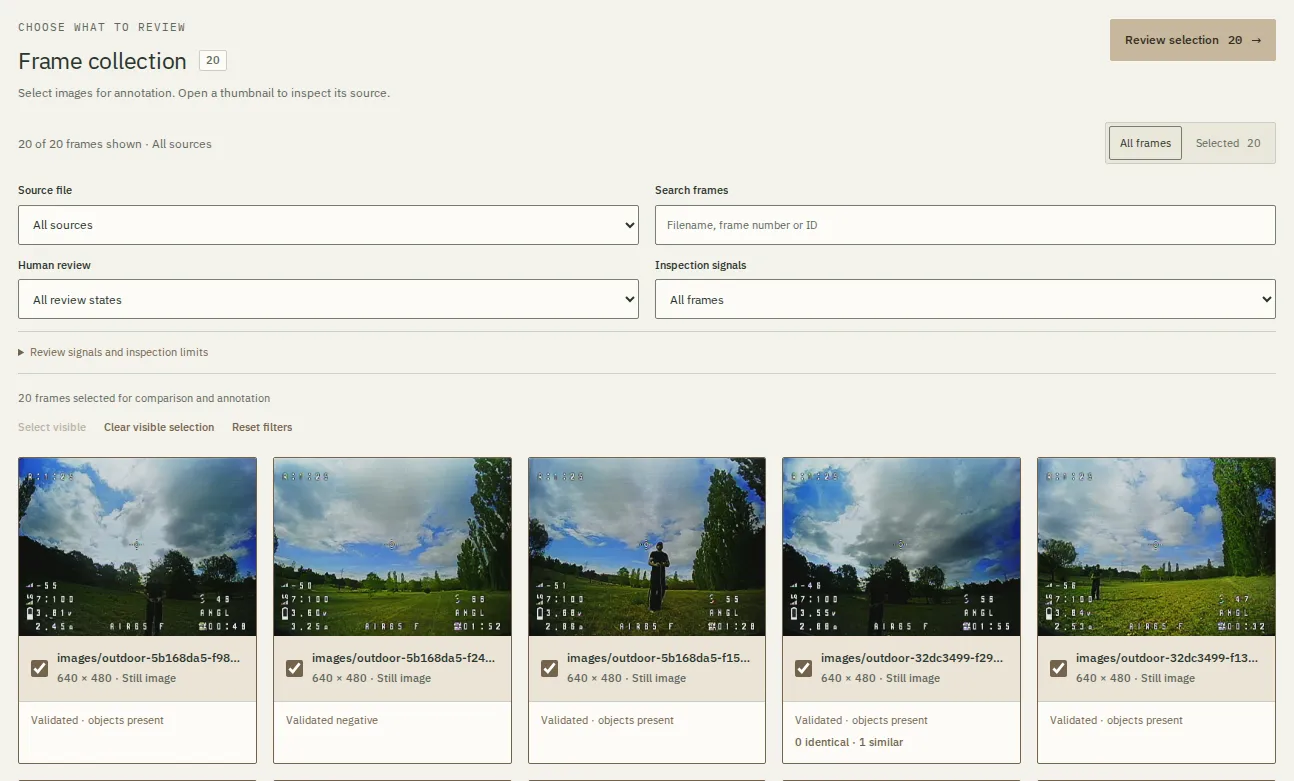
The first version focuses on object detection. I can import images and videos, select useful frames, review suggested annotations, build datasets and fine-tune detectors. I can then compare the trained model with the previous version and inspect its errors. One of the first uses has been improving person detection for argos. I trained a detector in iris, exported it and tested it in argos on recorded flights to compare it with the original model.