home

ARGOS

Aim to turn operator intent into autonomous drone missions

What i'm building

I’m building ARGOS so an operator can give a drone a mission and let the drone do it by itself. I’m starting with one drone and simple missions, but the goal is mission autonomy with either a single drone or a swarm depending on what’s needed.

Timeline

  1. Bought my first drone and the hardware I needed to get started
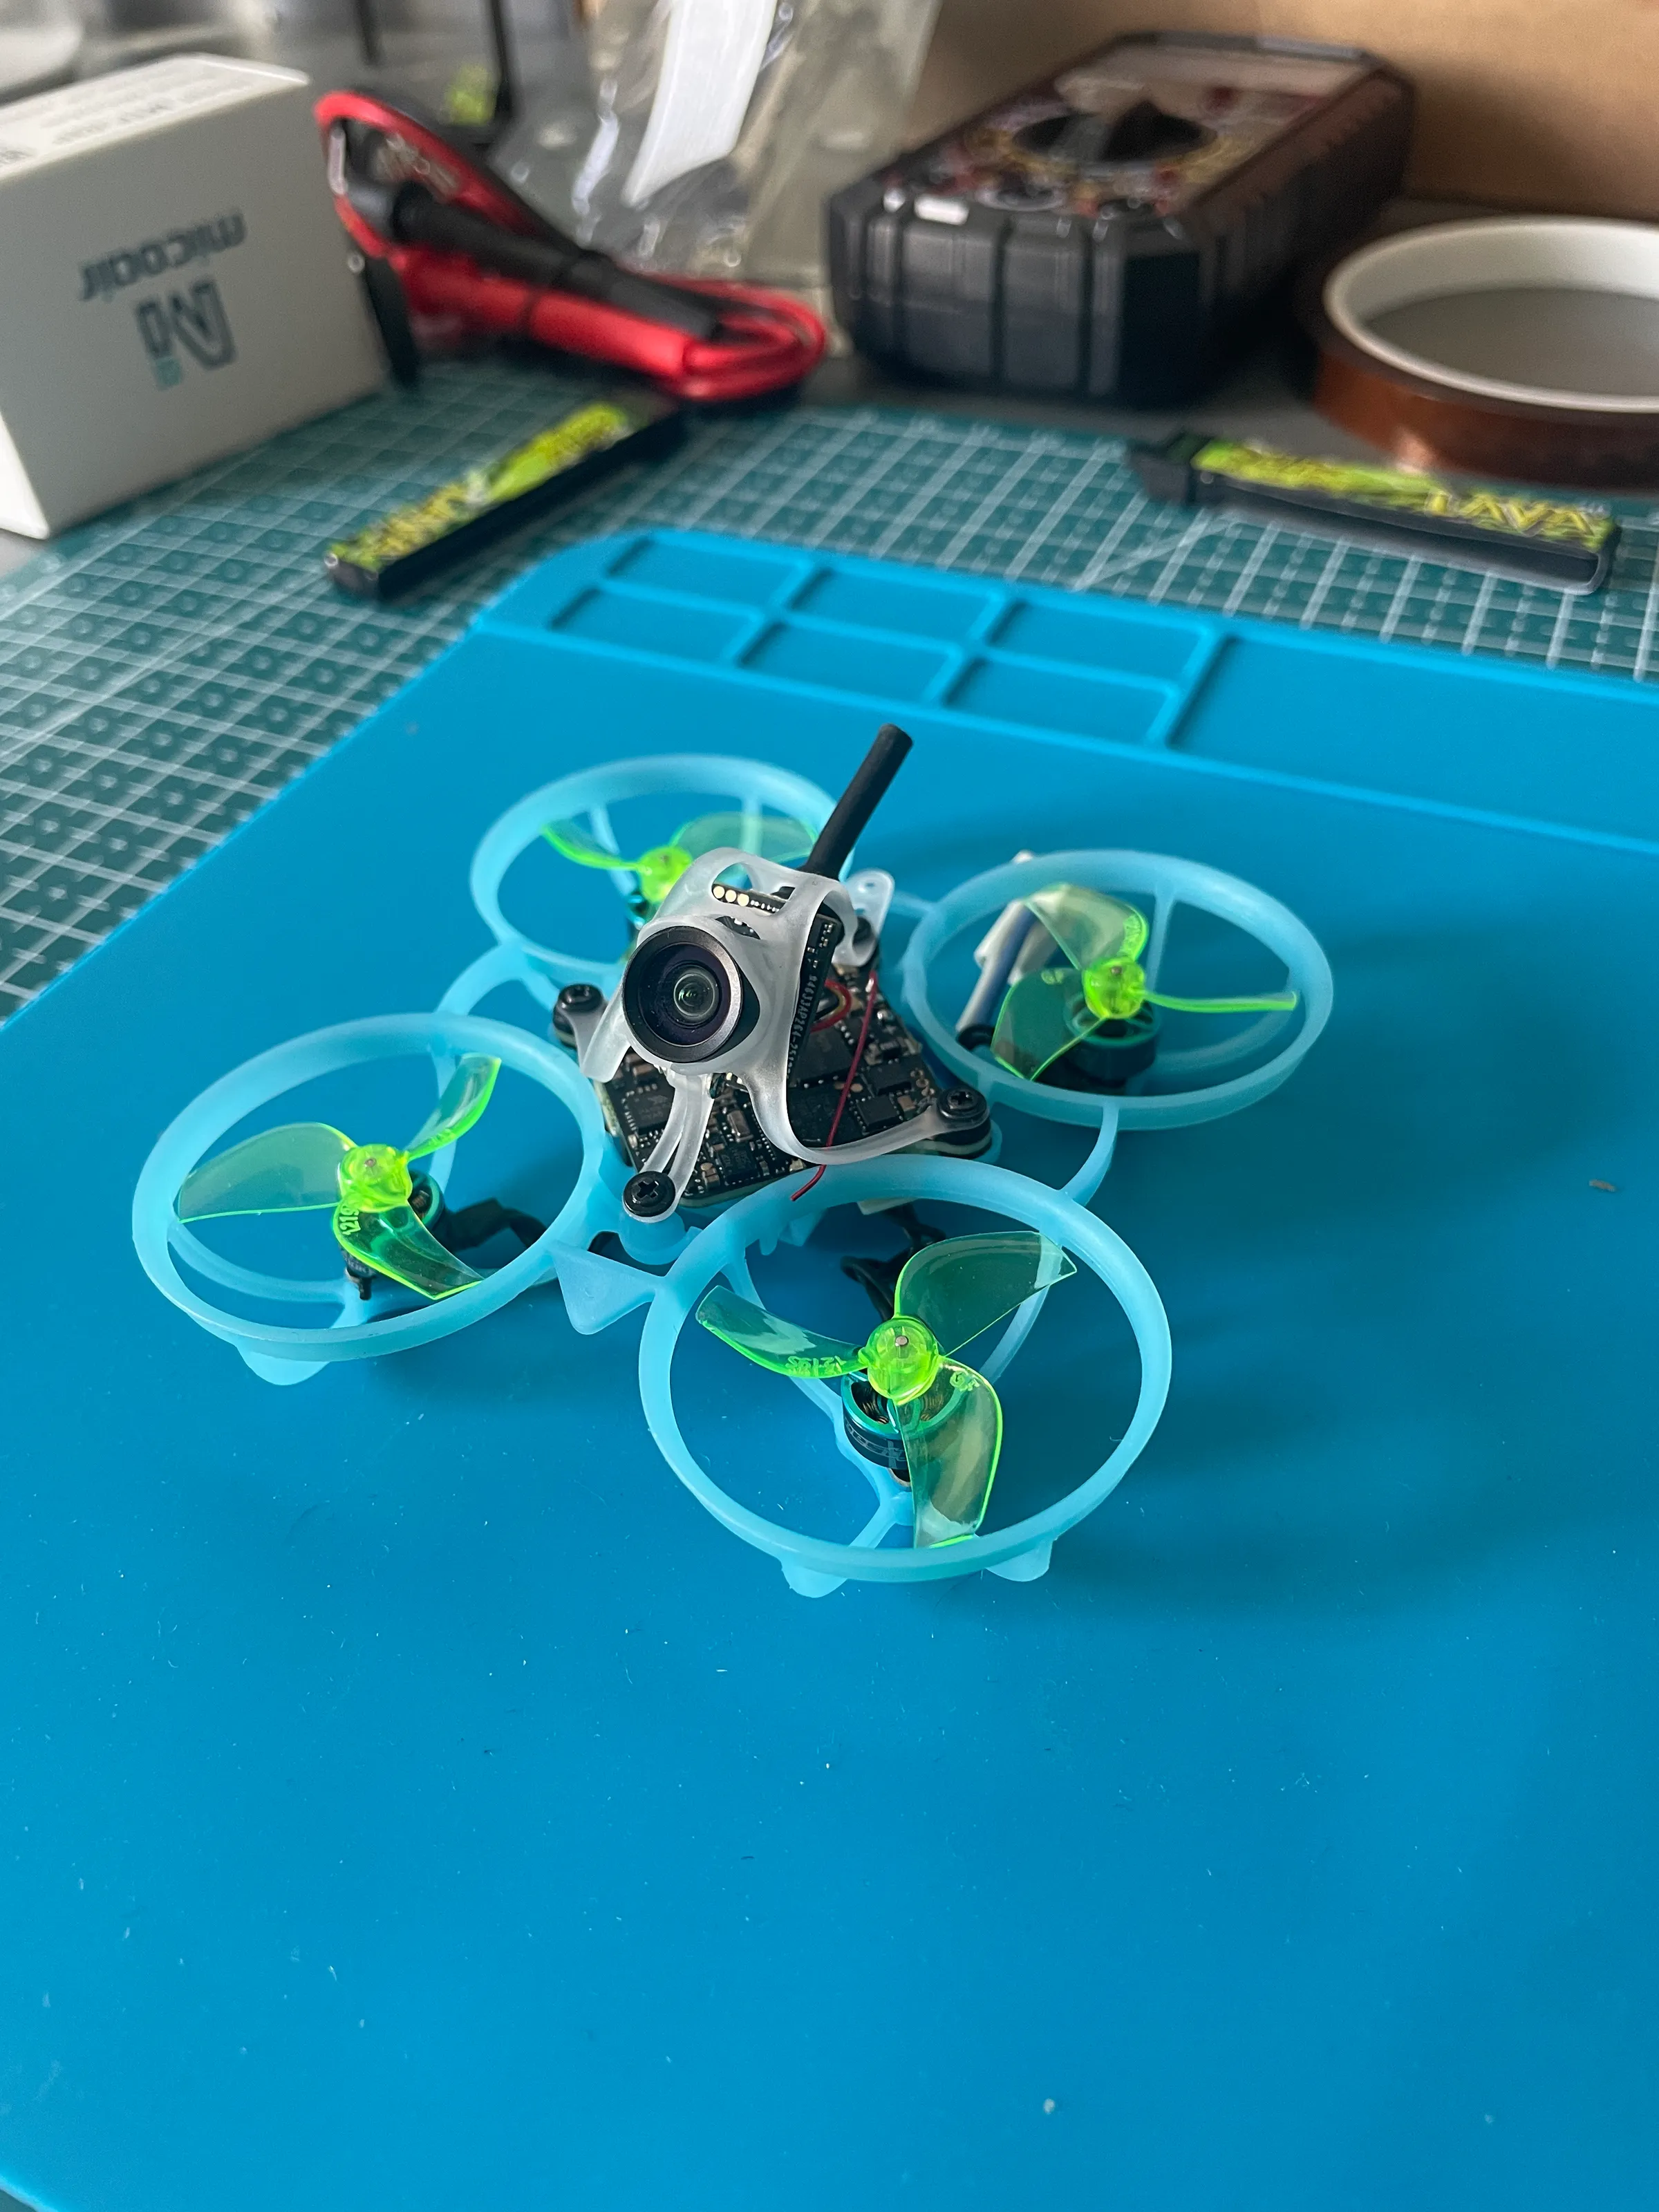
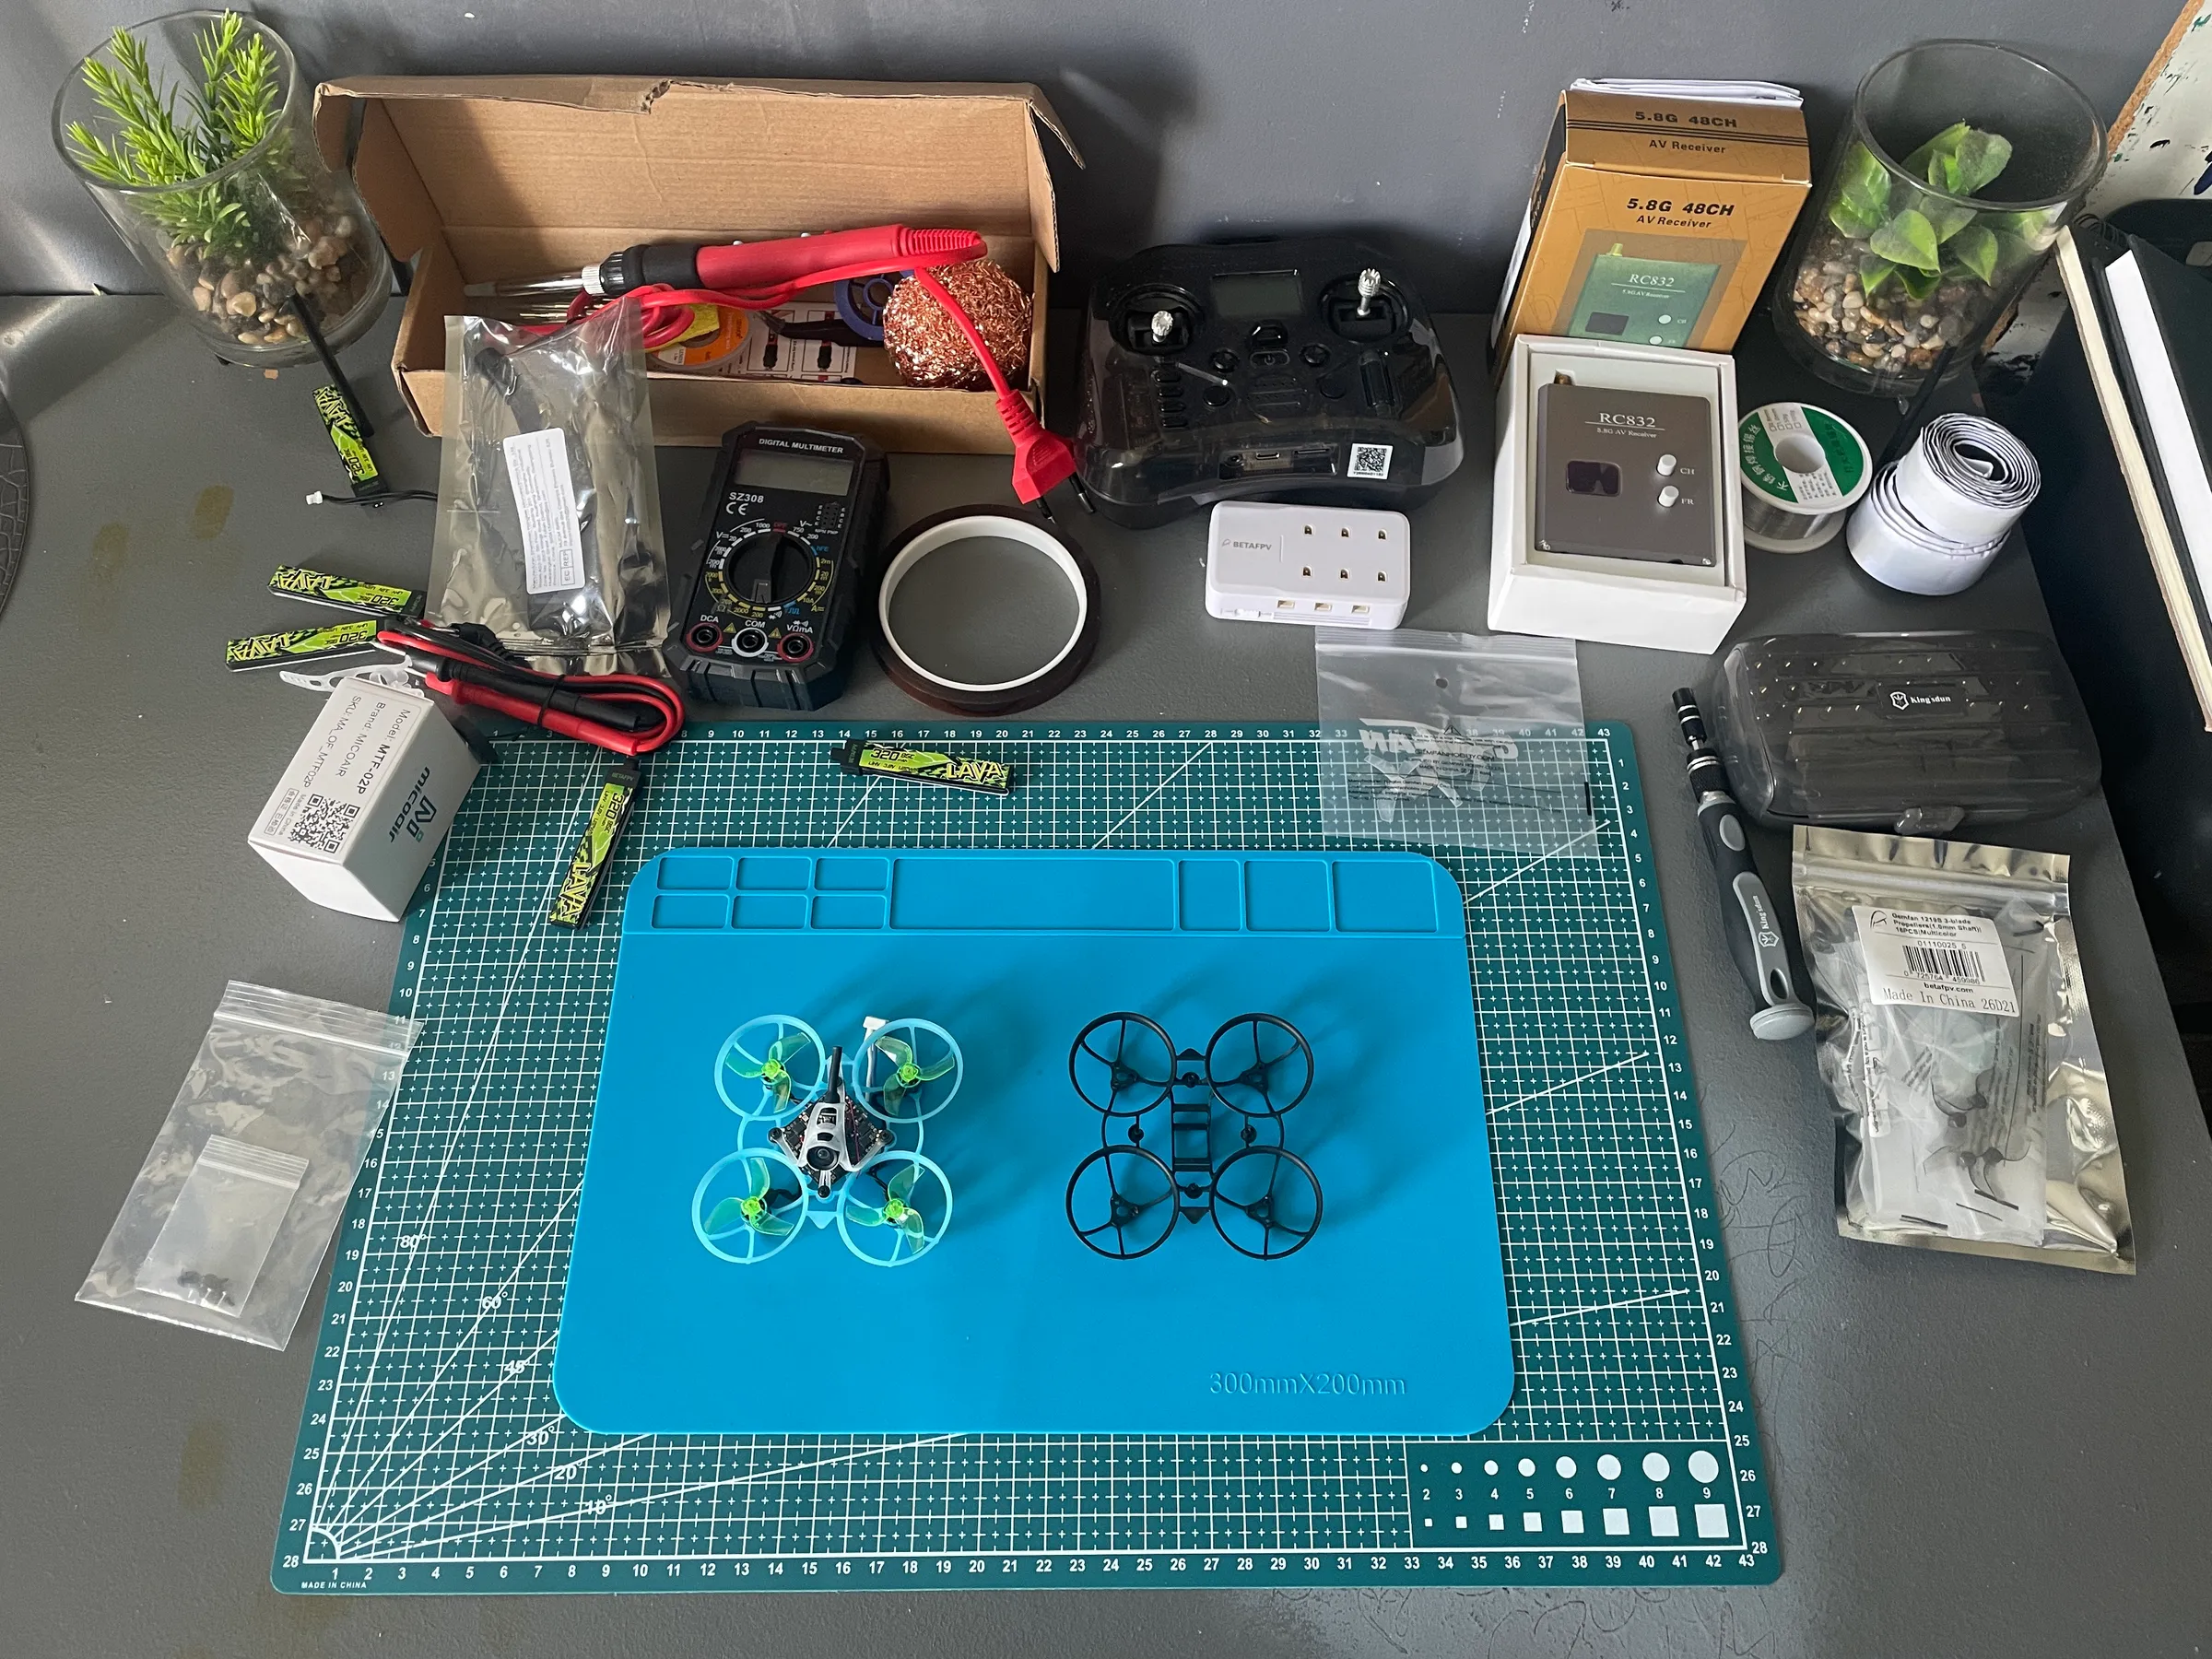
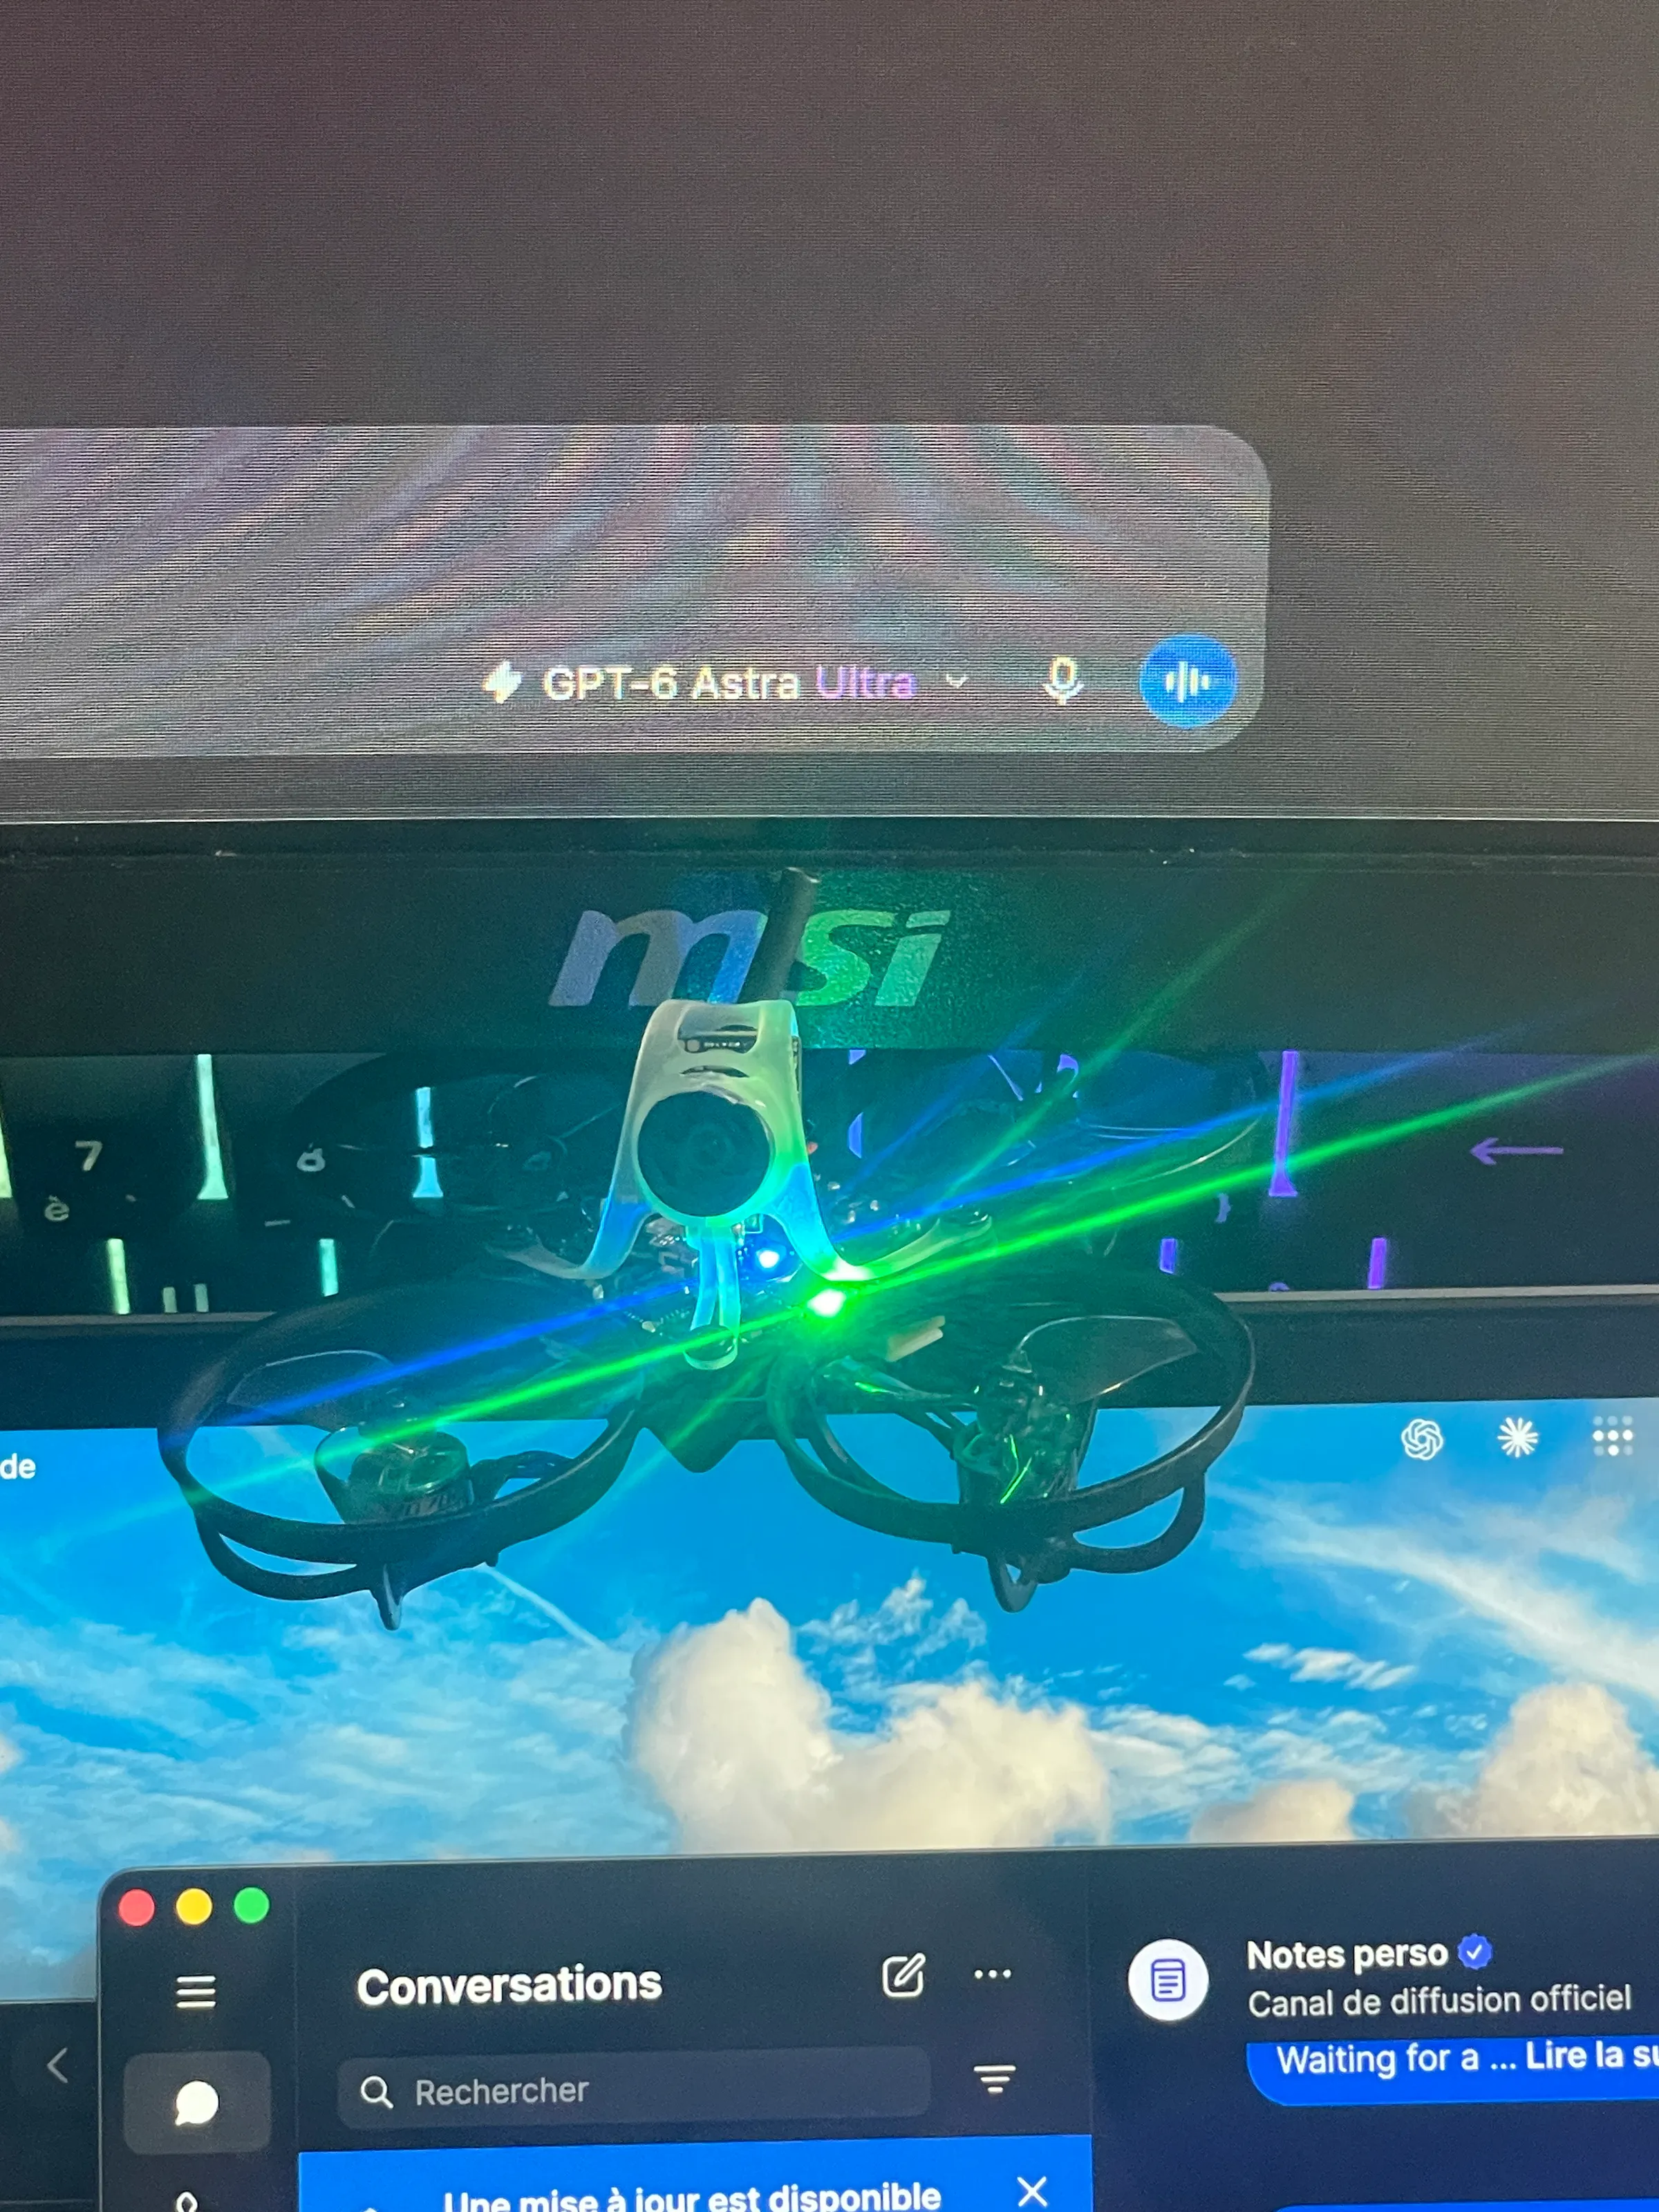
    BetaFPV Air65 II drone
    the invincible little guy
    Image — no description provided.

    asked on twitter which drone to buy first to get started with autonomous drone projects and decided to go with a BetaFPV Air65 II did some research on the basic gear I needed like the radio and the video receiver.
  2. The first argos interface

    Image — no description provided.
    Image — no description provided.

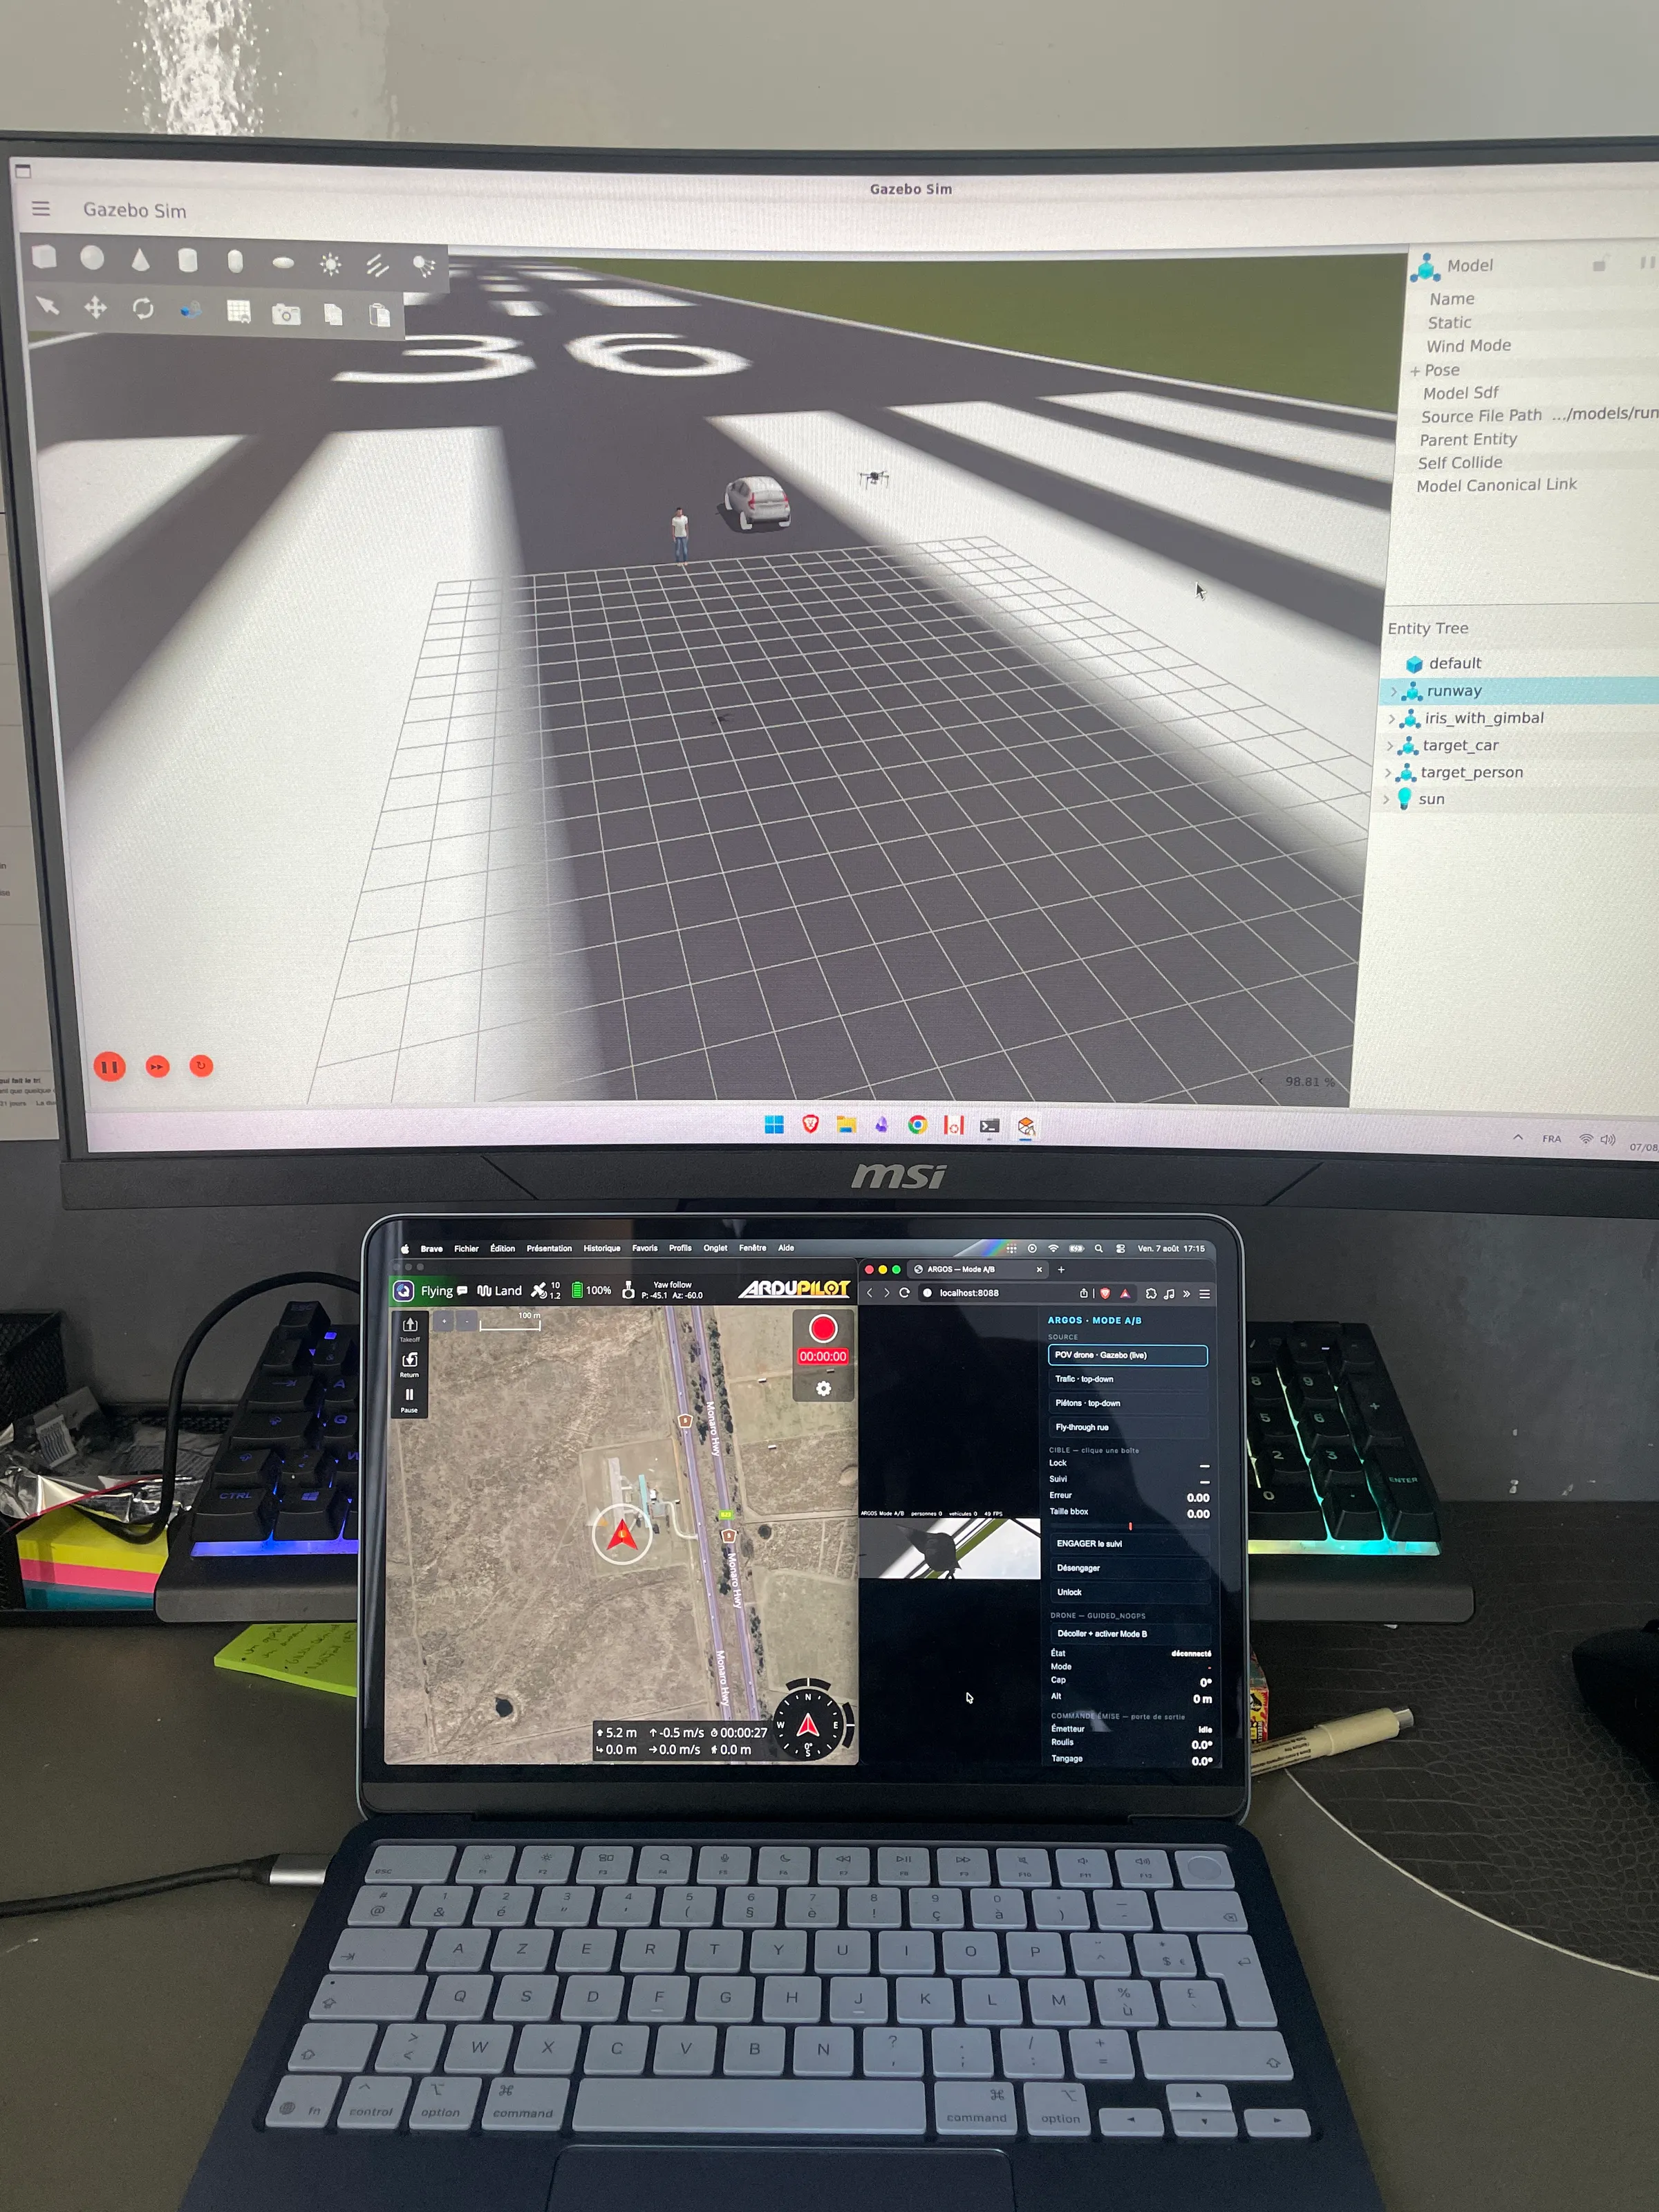
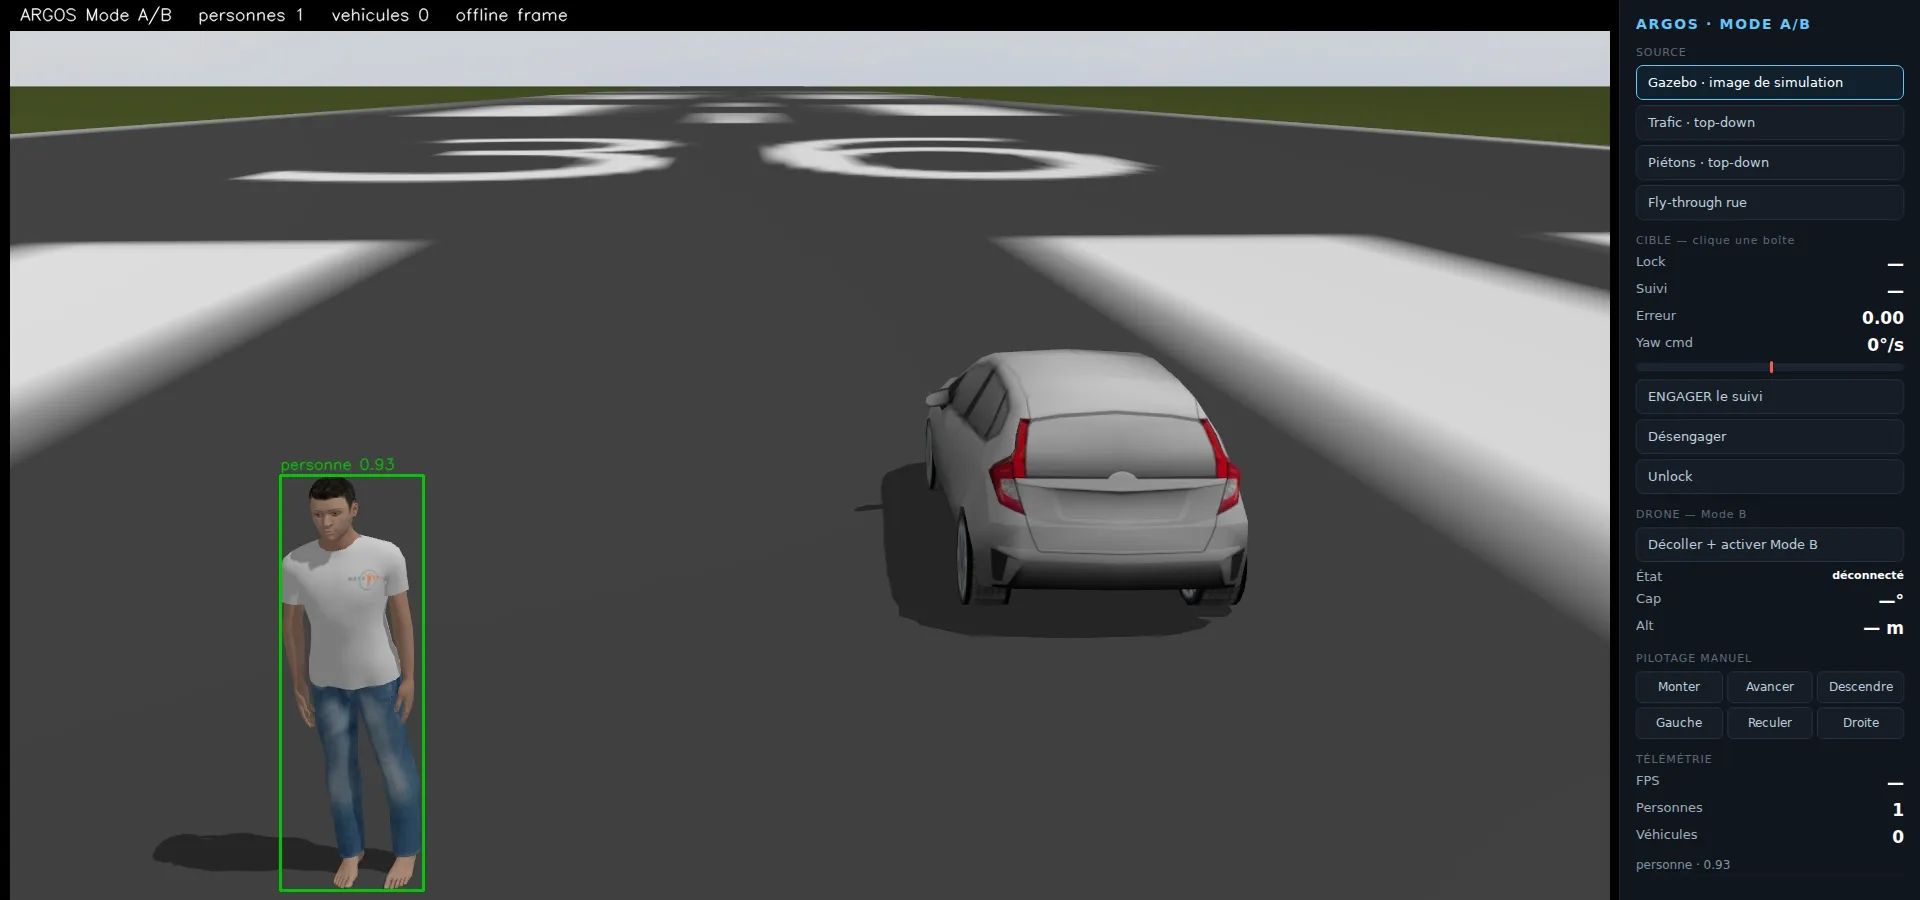
    the old interface with Gazebo and QGroundControl. the first tests trying to make a simulated drone fly on its own, lock onto a target and keep a distance from it.

  3. Built my first fpv drone

    Image — no description provided.
    a
    a
    a

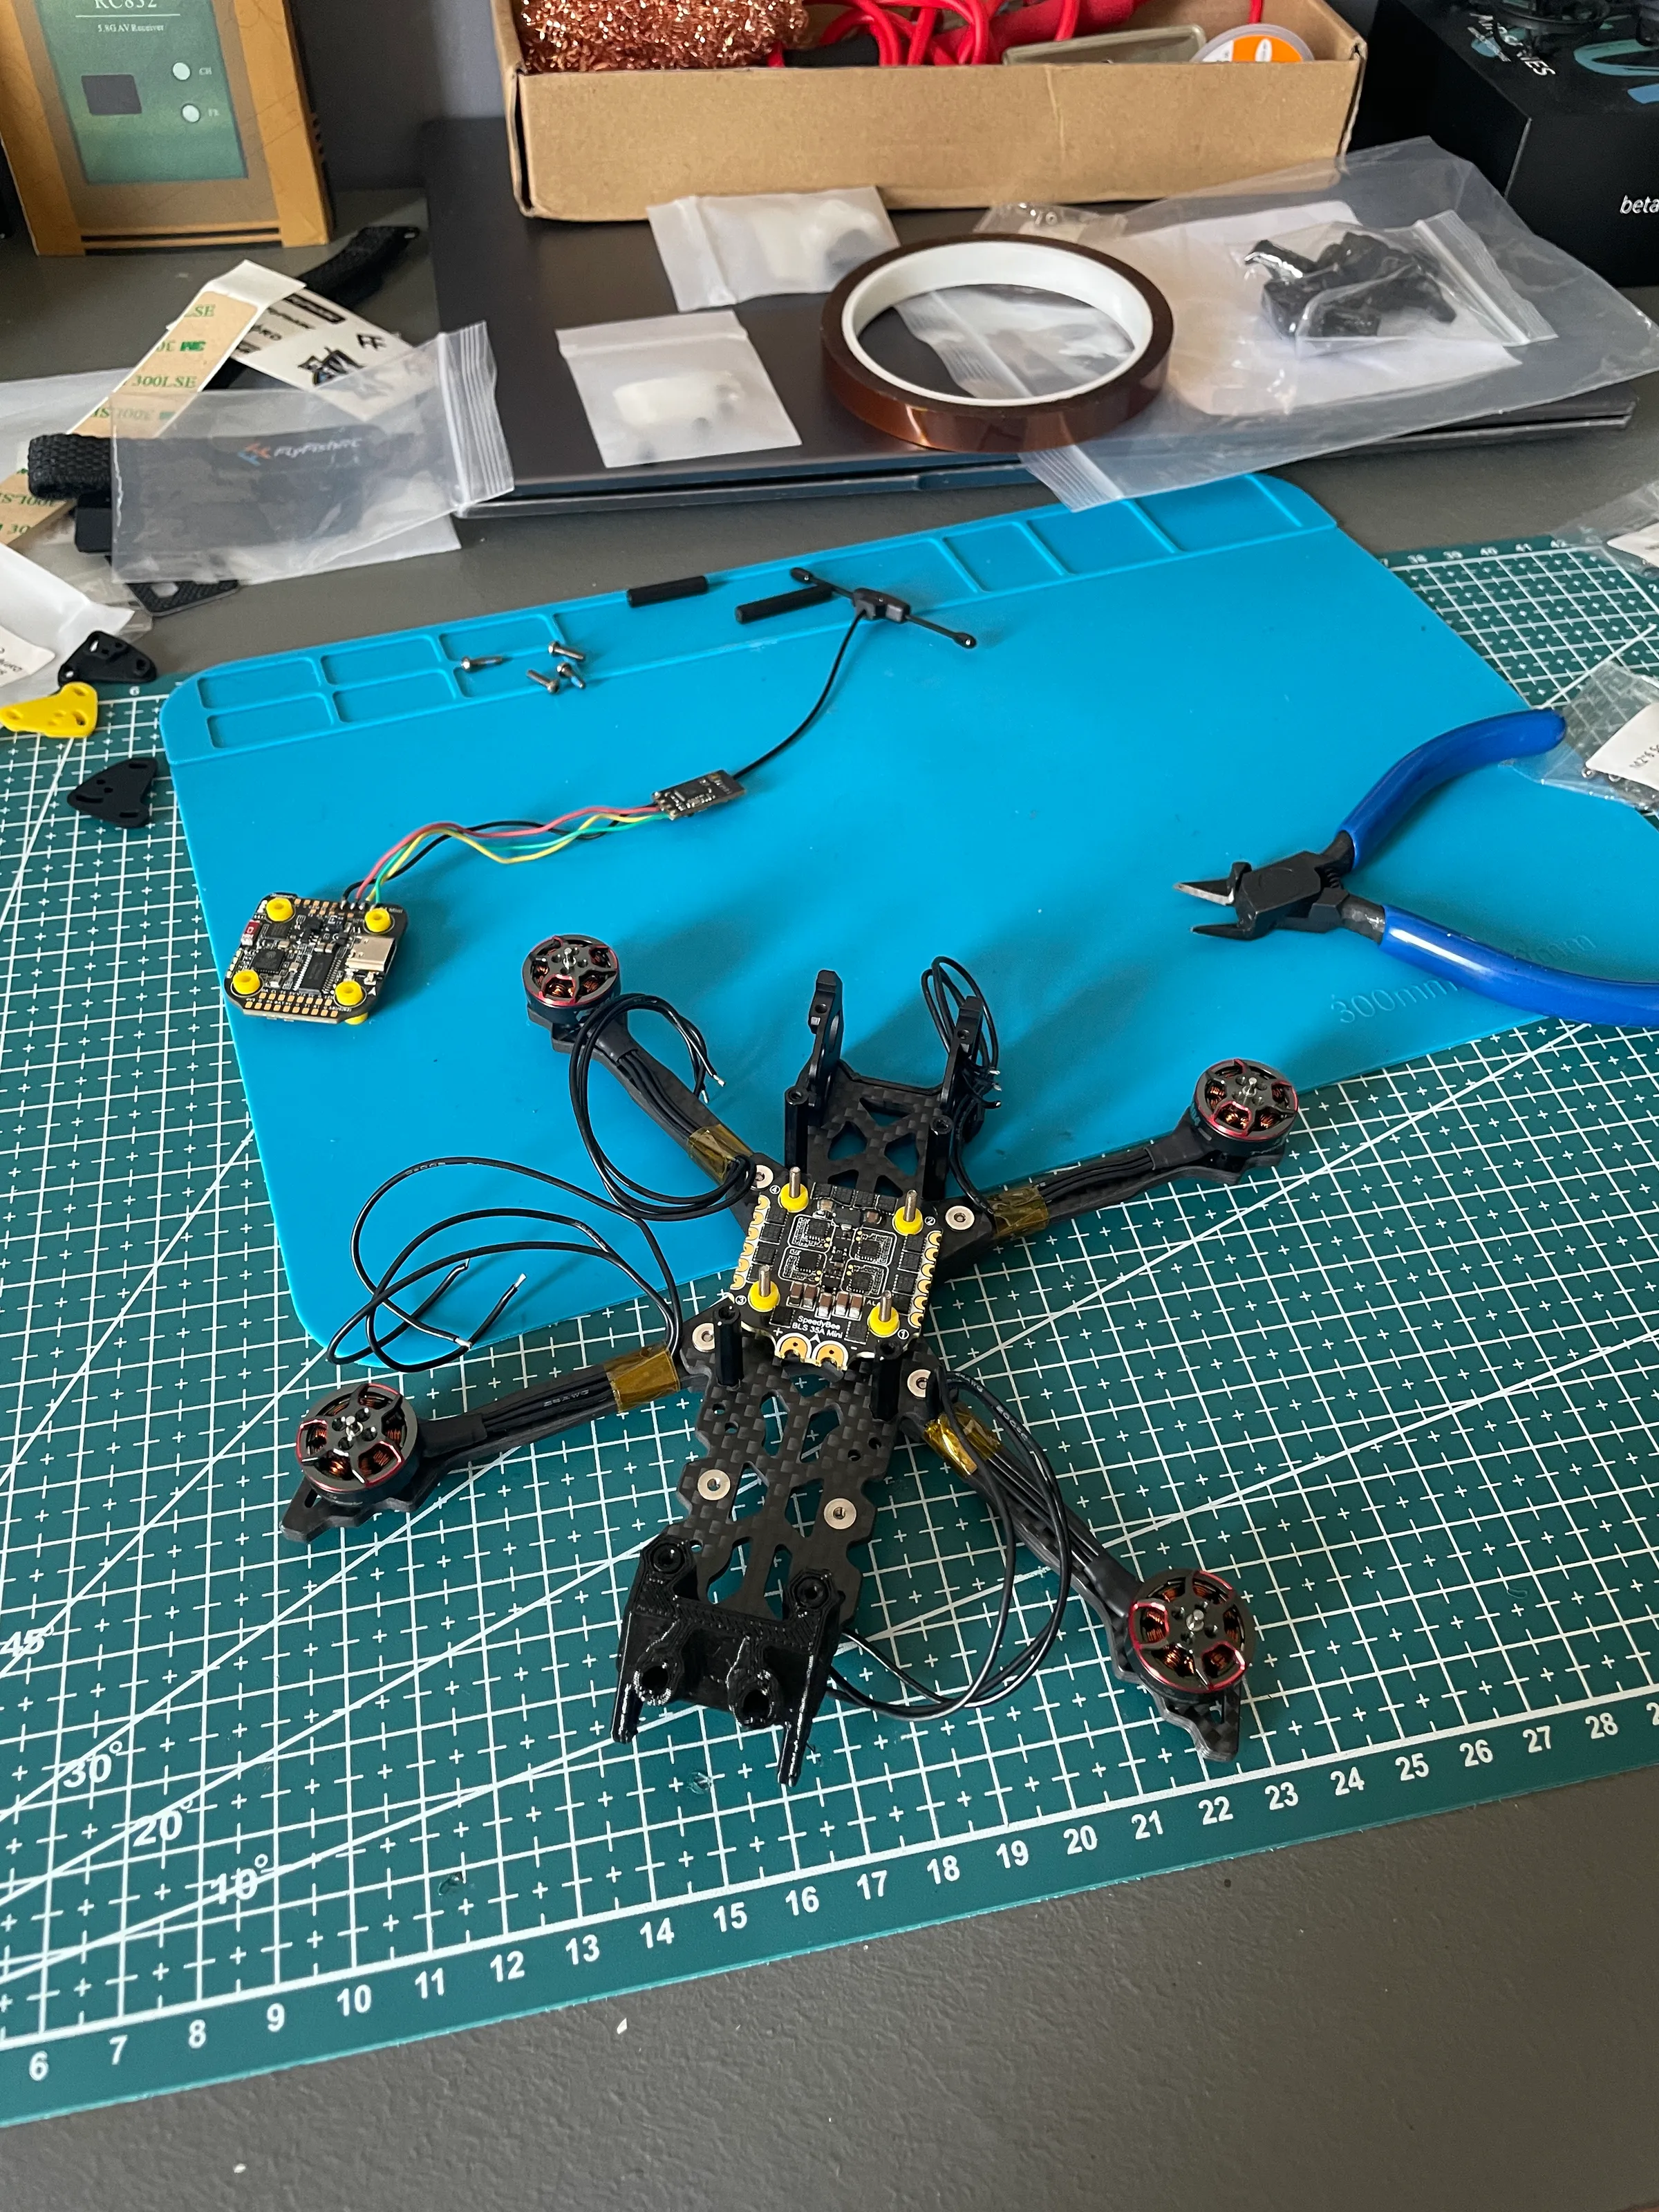
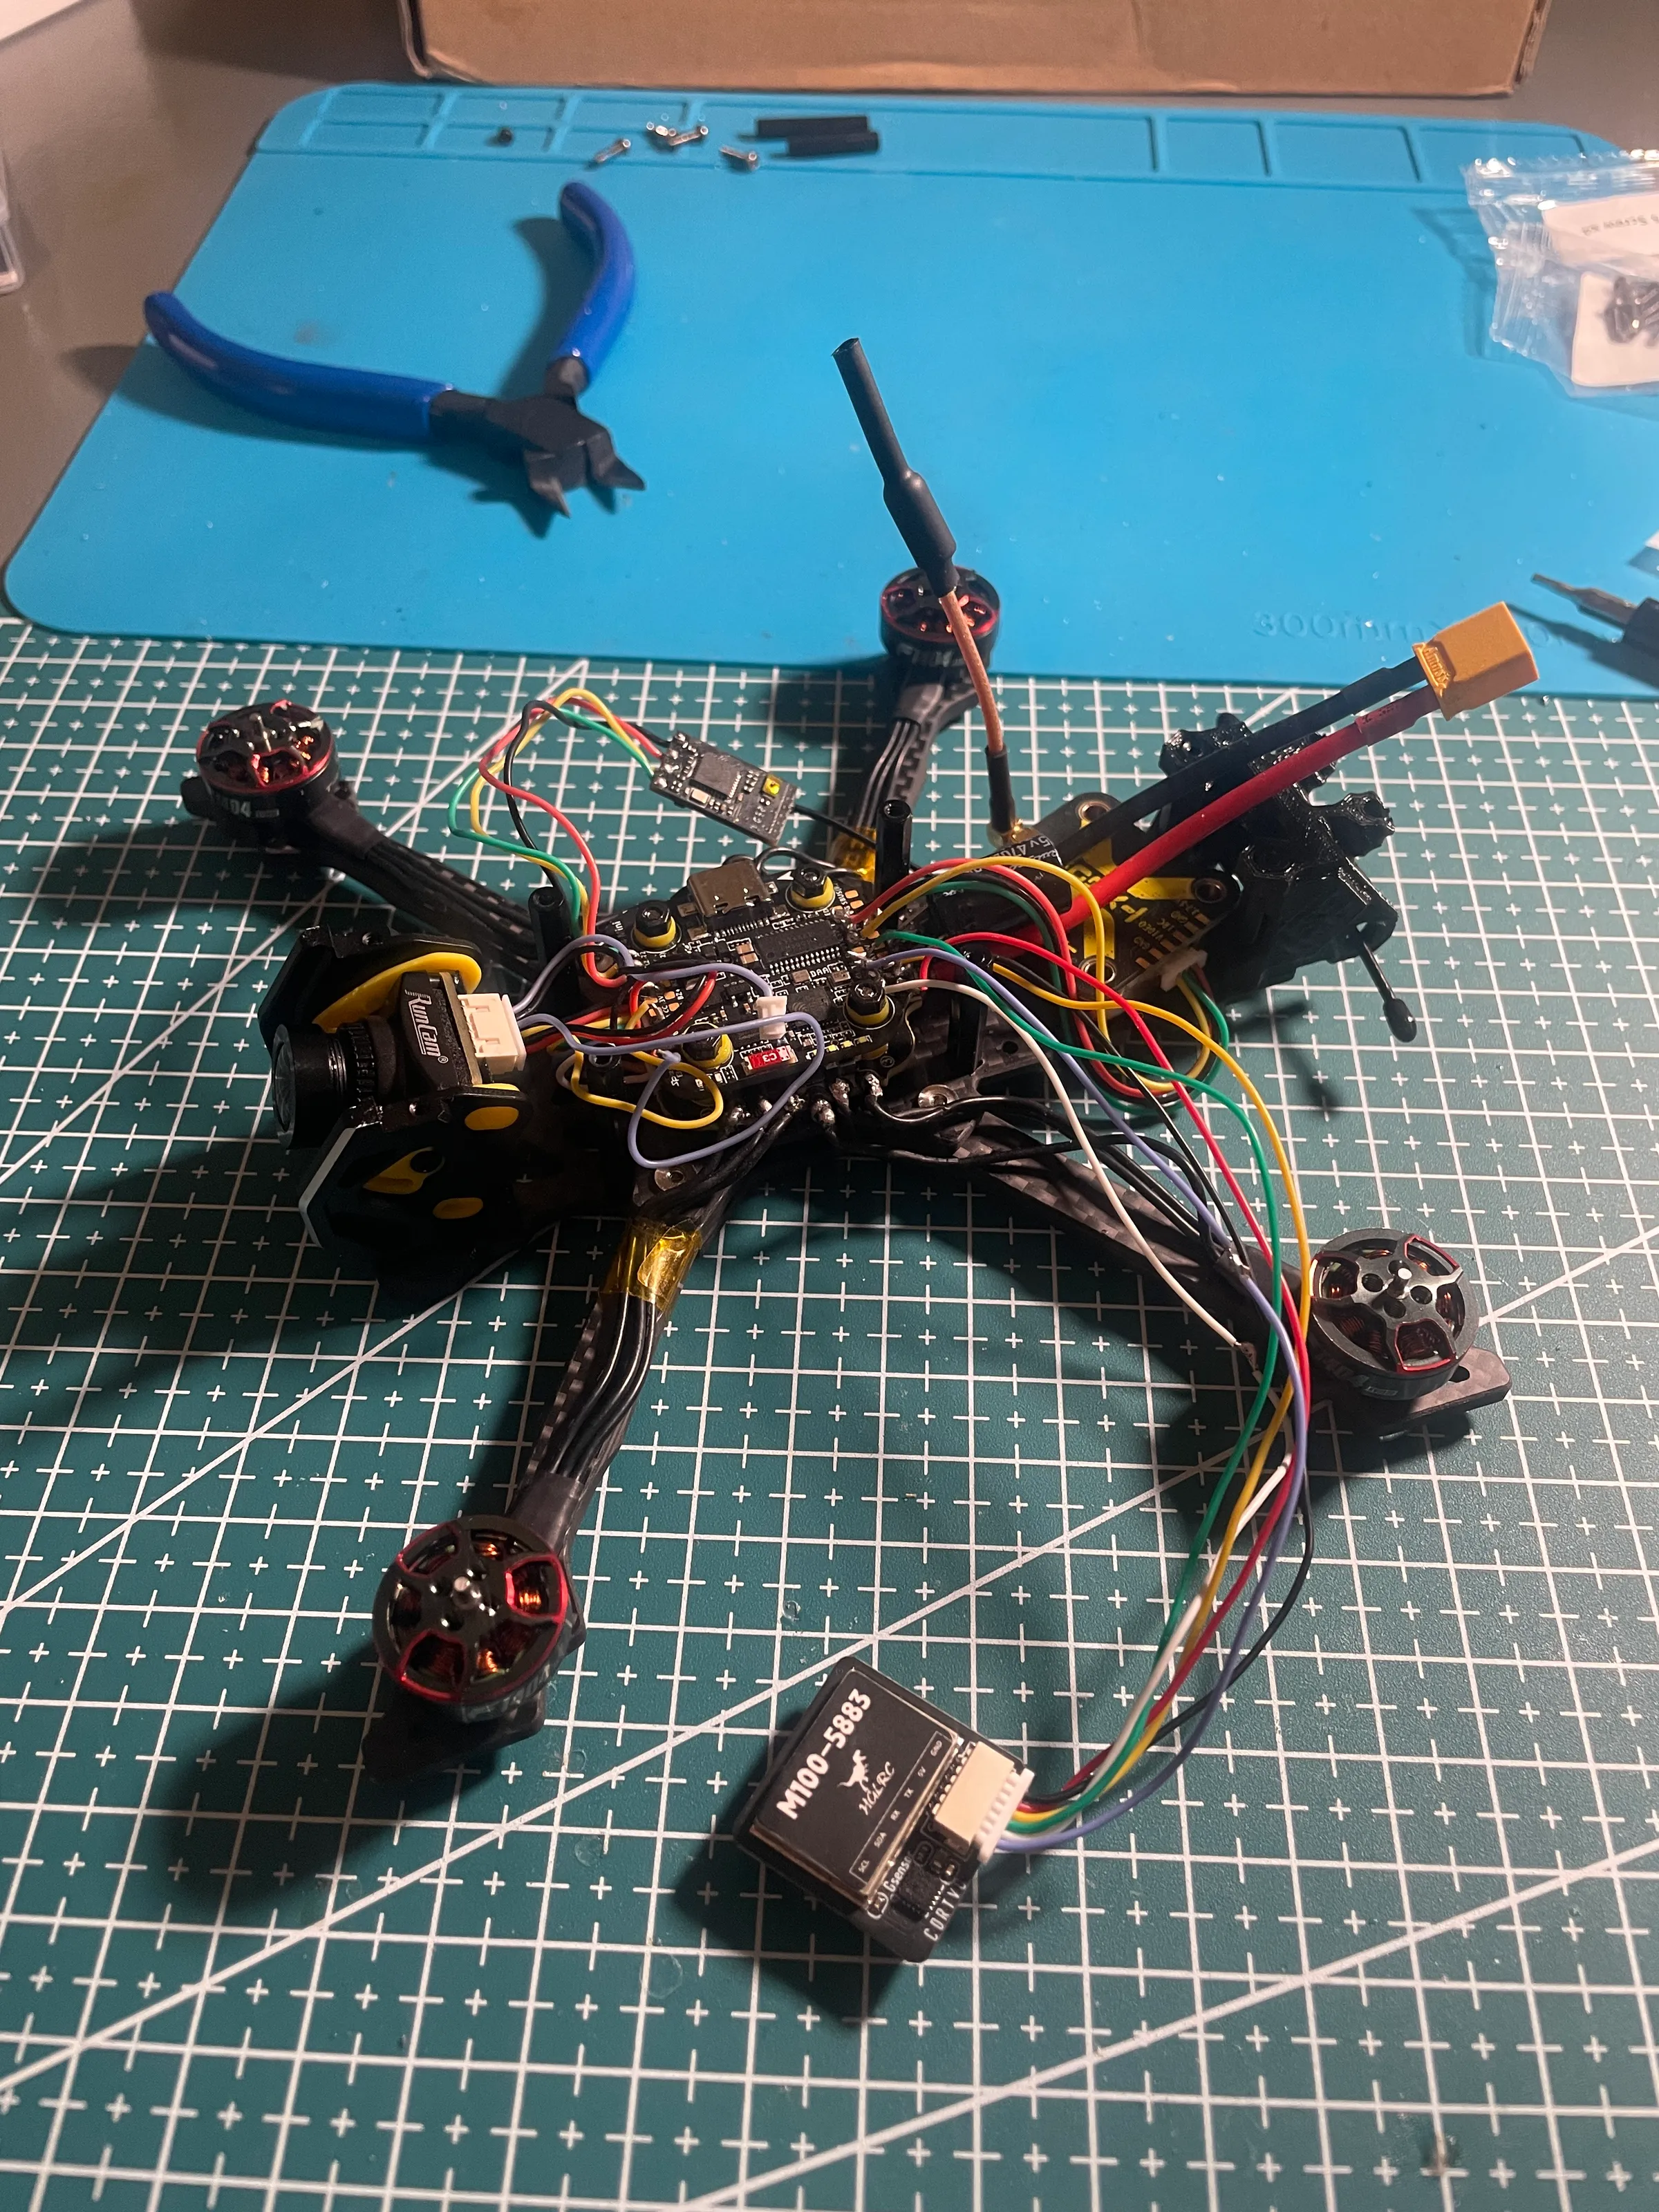
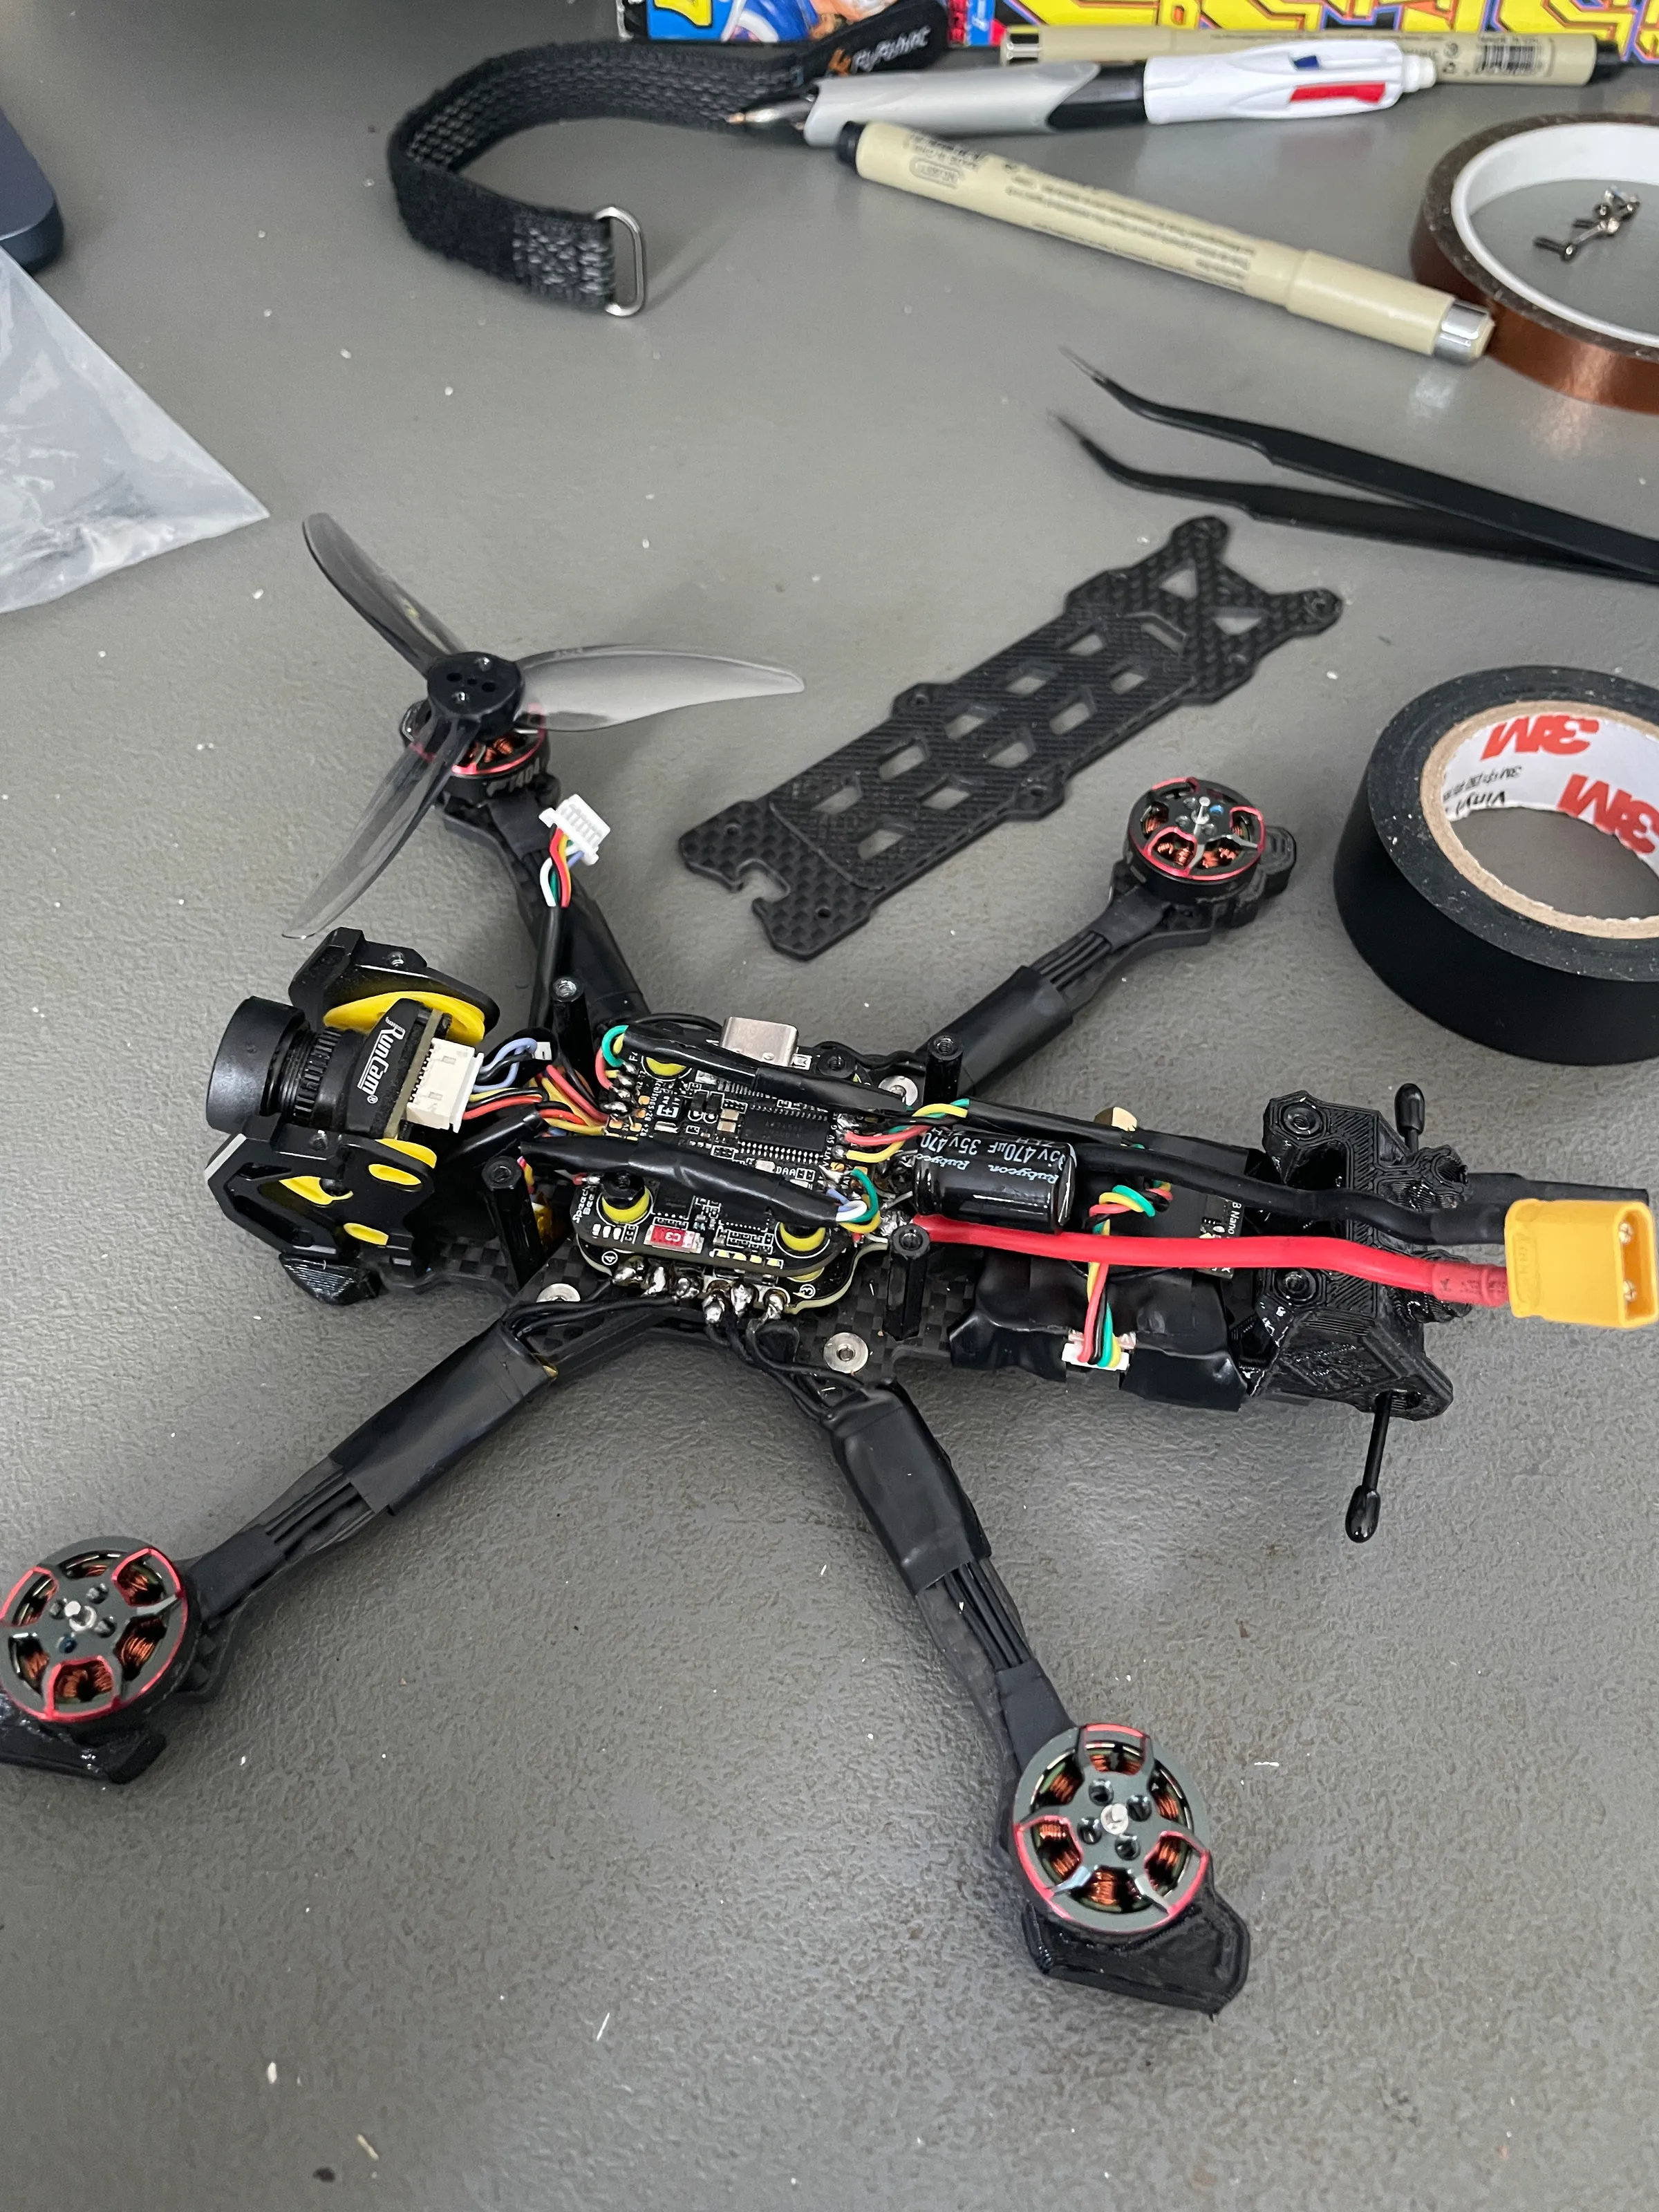
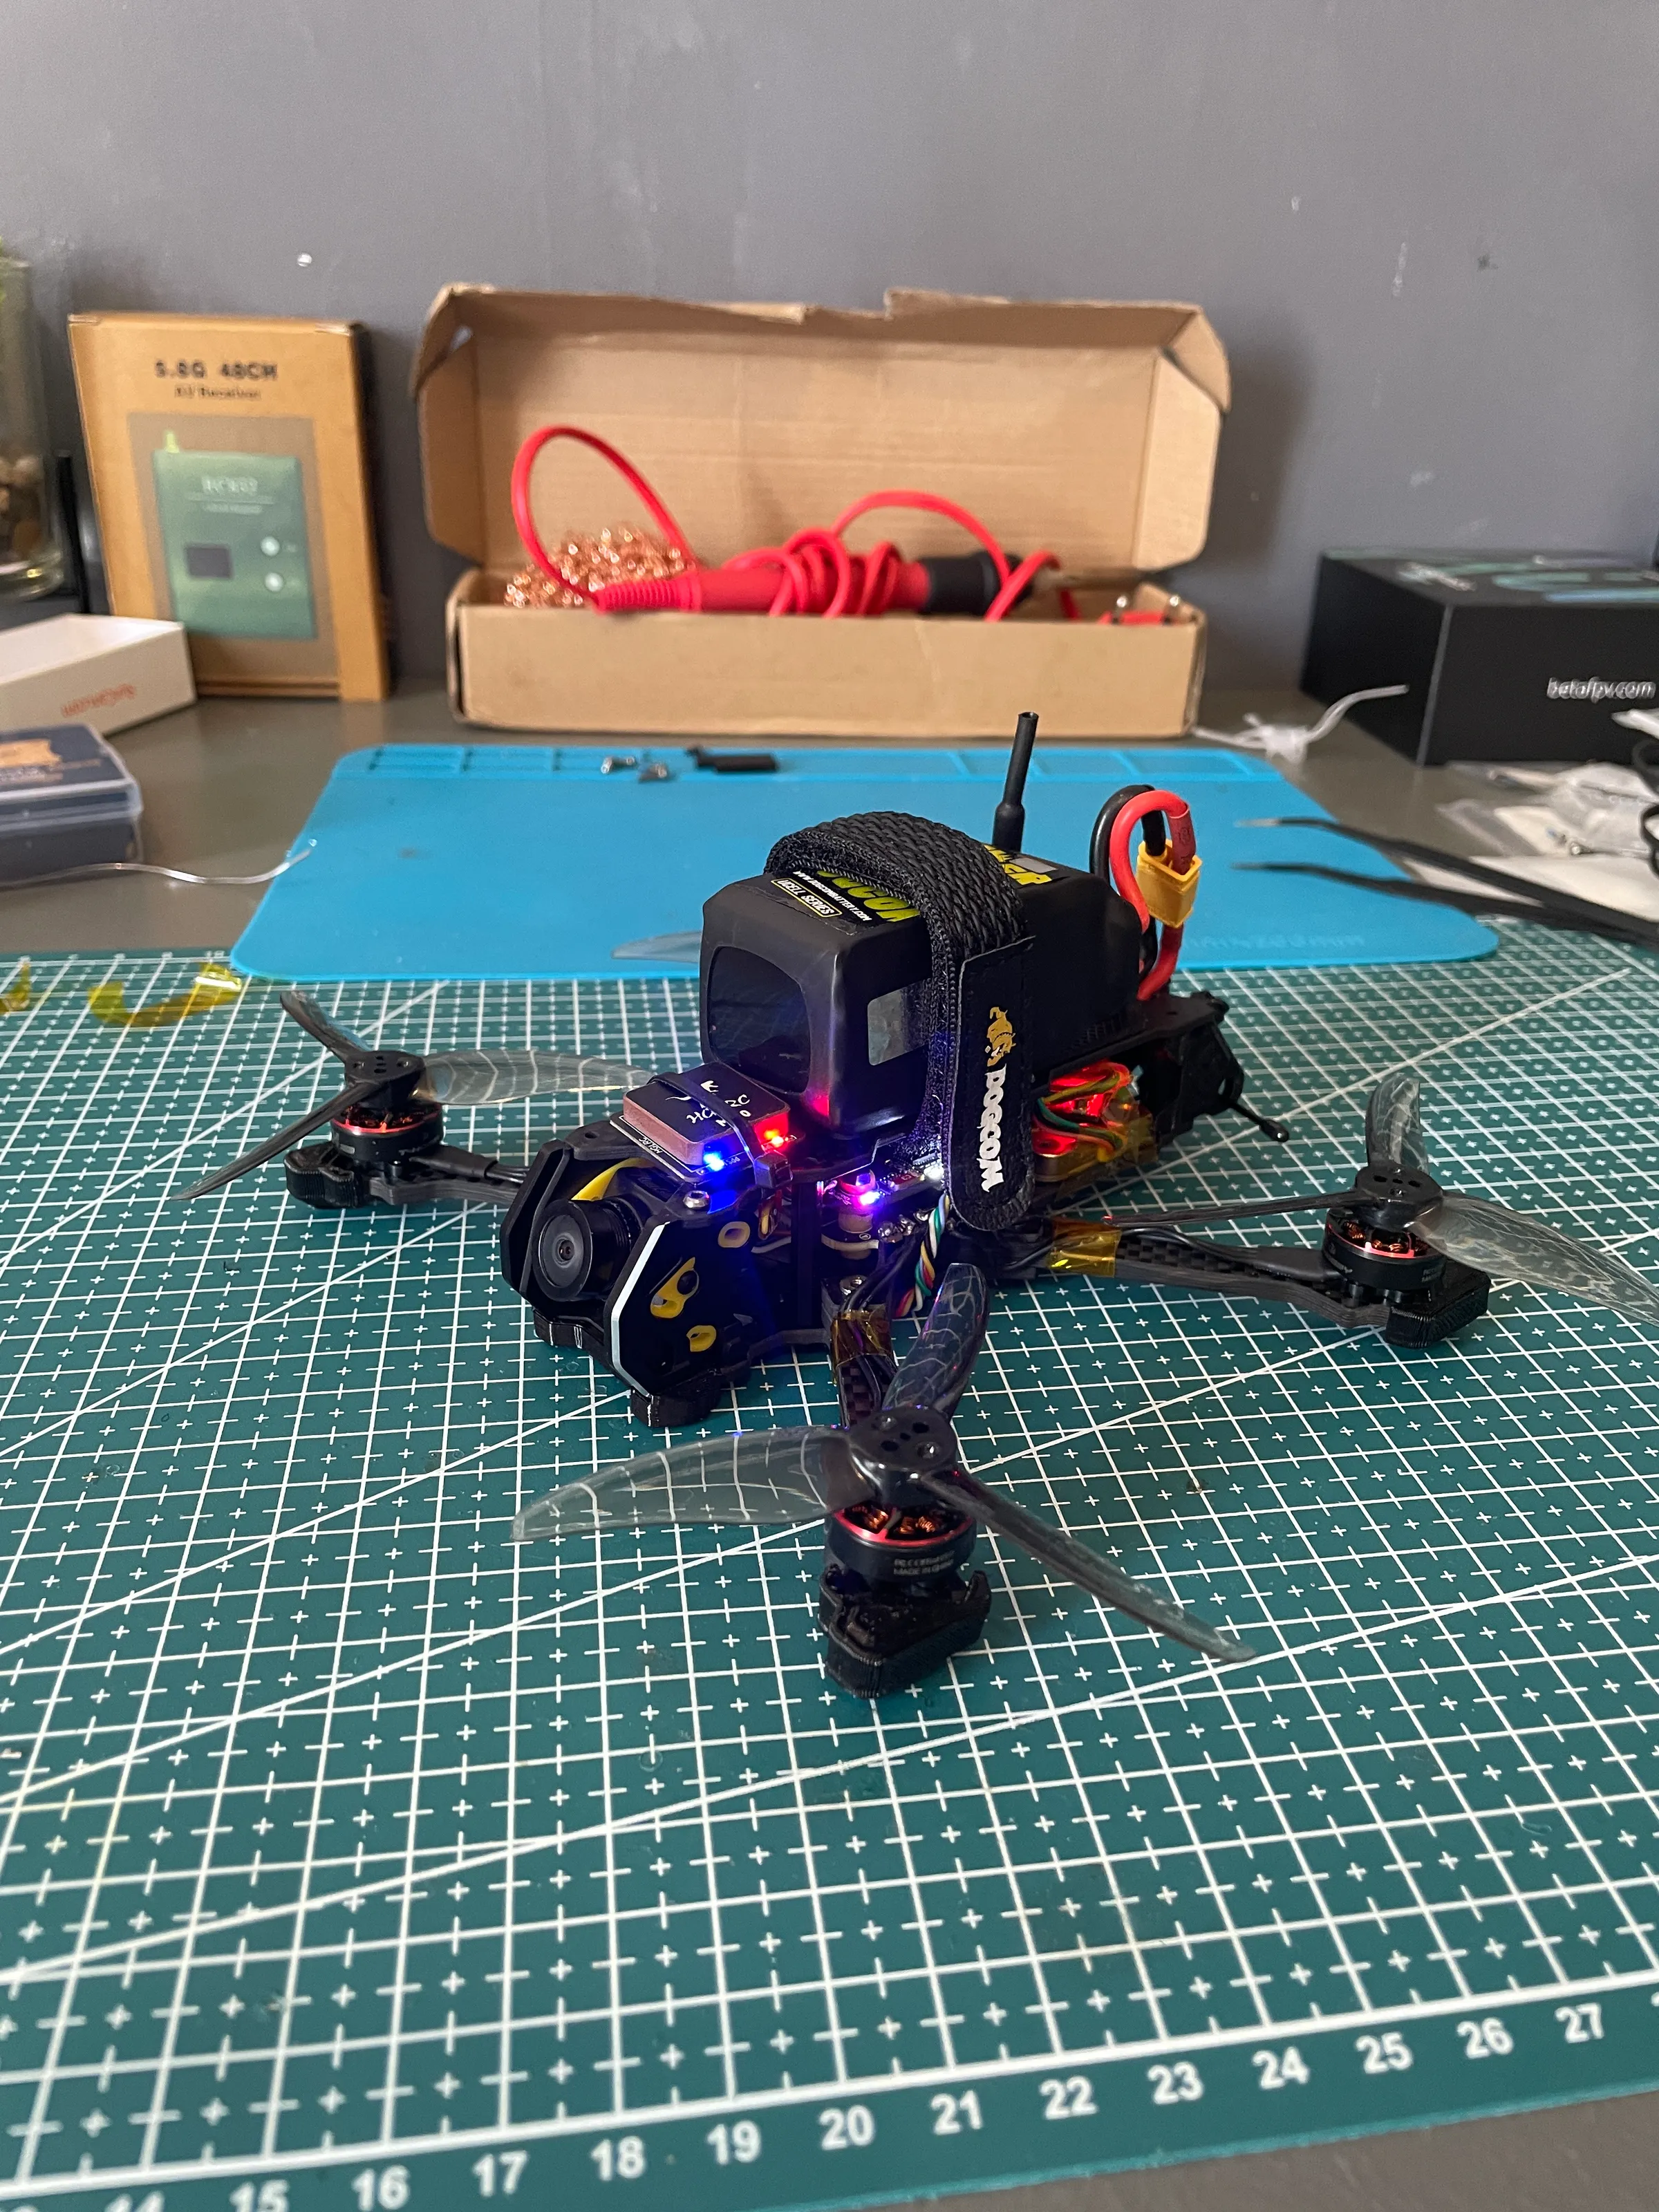
    built my first fpv drone to run ArduPilot and have something closer to the drones used in industry.

  4. Discovering hardware problems

    spent too much time on a problem that was making my drone wobble. In the end it was an obvious tuning change that solved it. after that I also had a screw I couldn’t get out which stopped me from accessing the components.

  5. New argos interface and MAVLink features

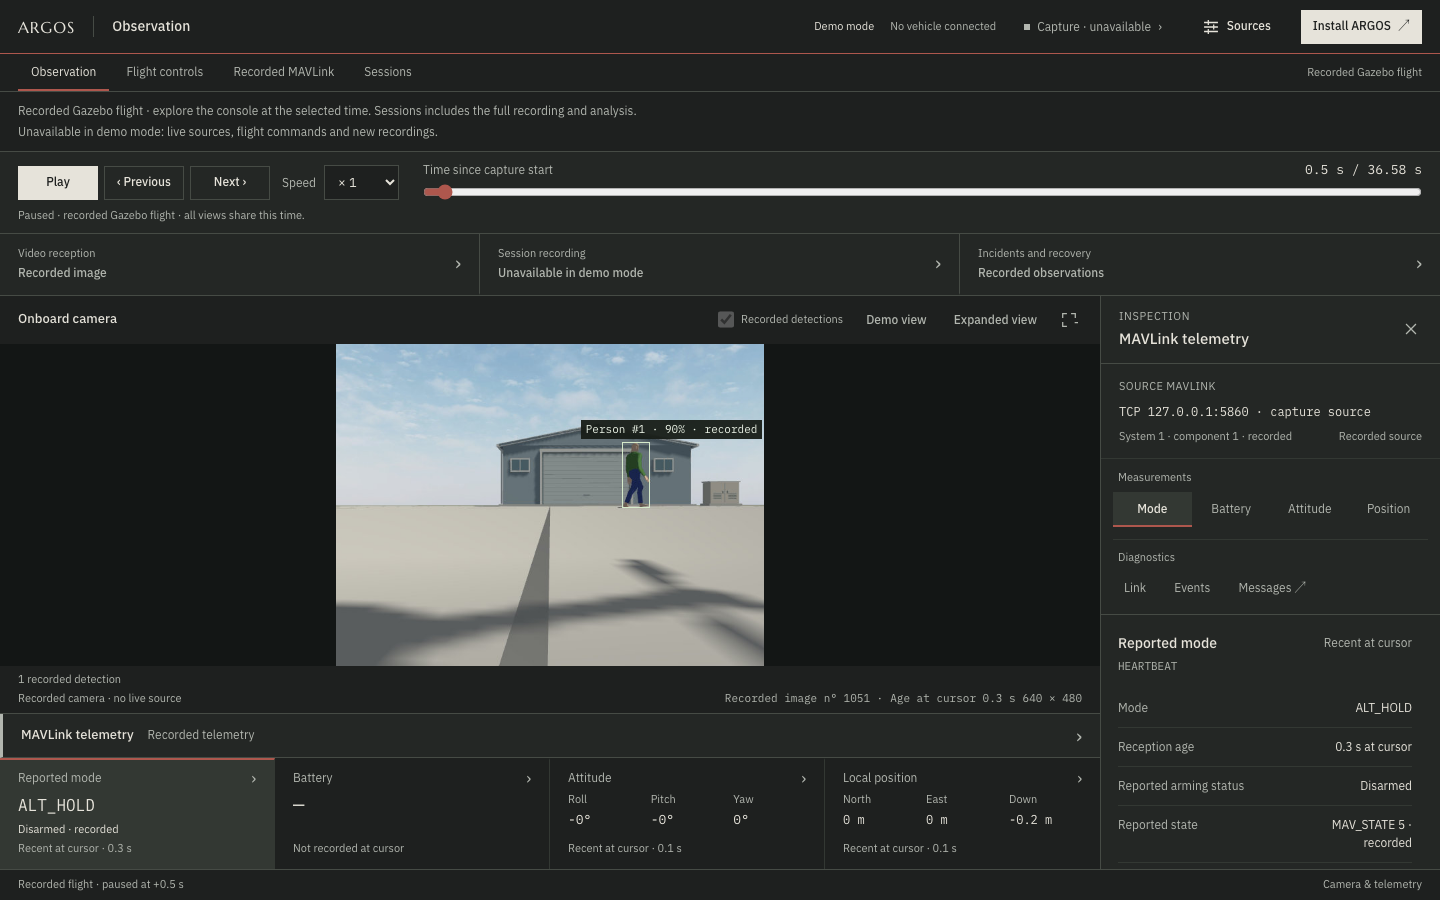
    replaying a simulated flight
    MAVLink messages and reception history

    rebuilt the argos interface, added MAVLink features and did the first SITL and HITL tests.

  6. Bedroom flights and radio tests

    Image — no description provided.
    Image — no description provided.

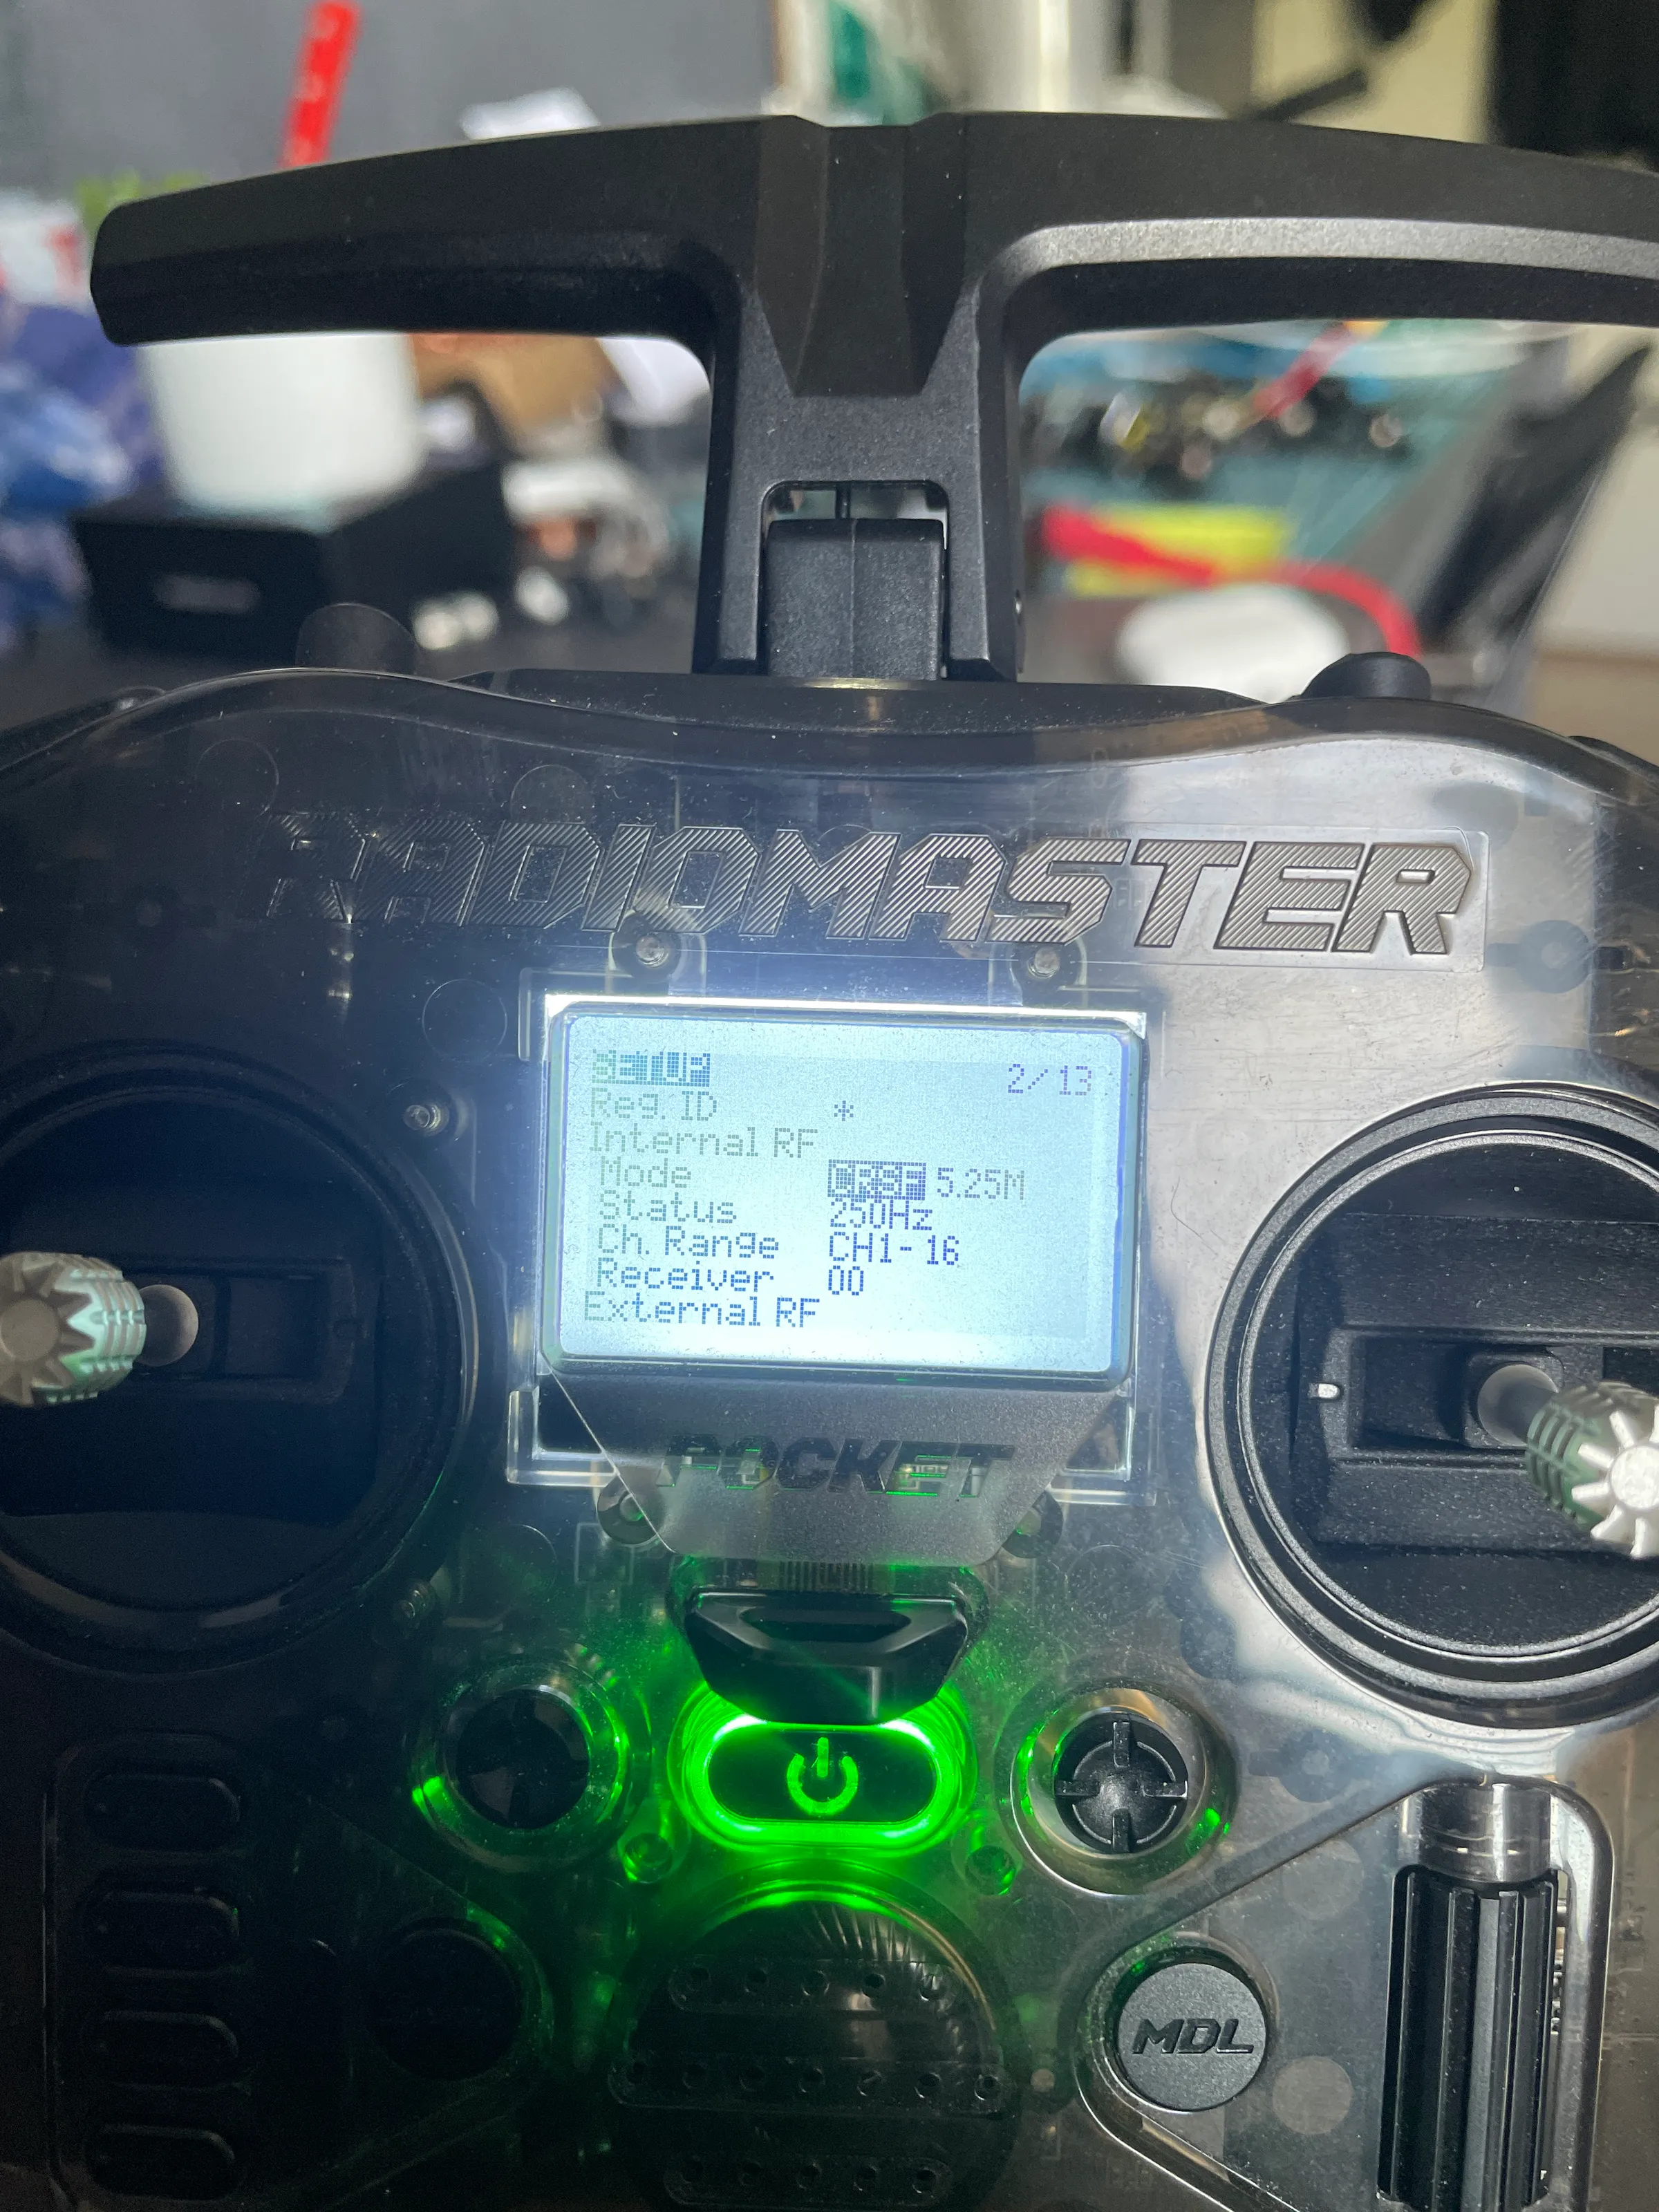
    connected argos to my radio and tested the yaw control in my bedroom before going outside.

  7. Outdoor flights with argos controlling yaw

    demo video
    Image — no description provided.
    Image — no description provided.
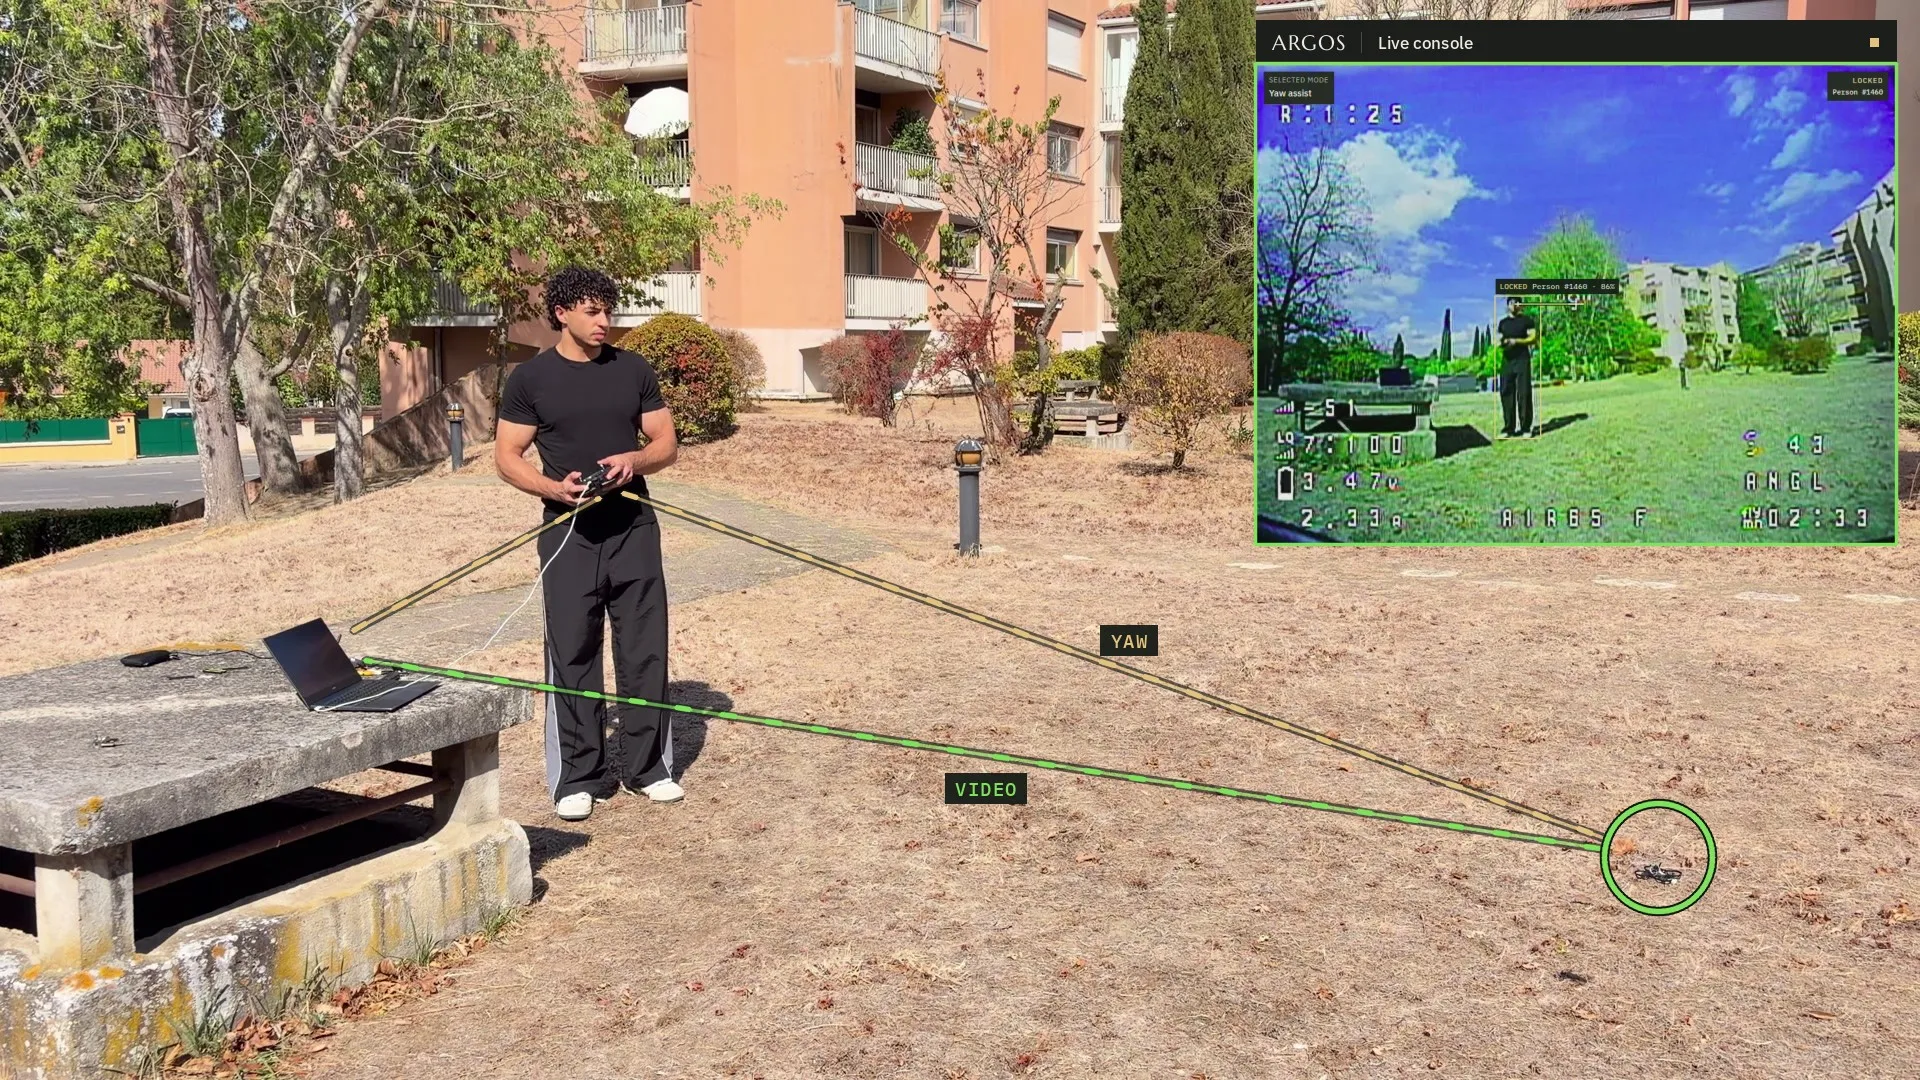
    outside setup without an internet connection

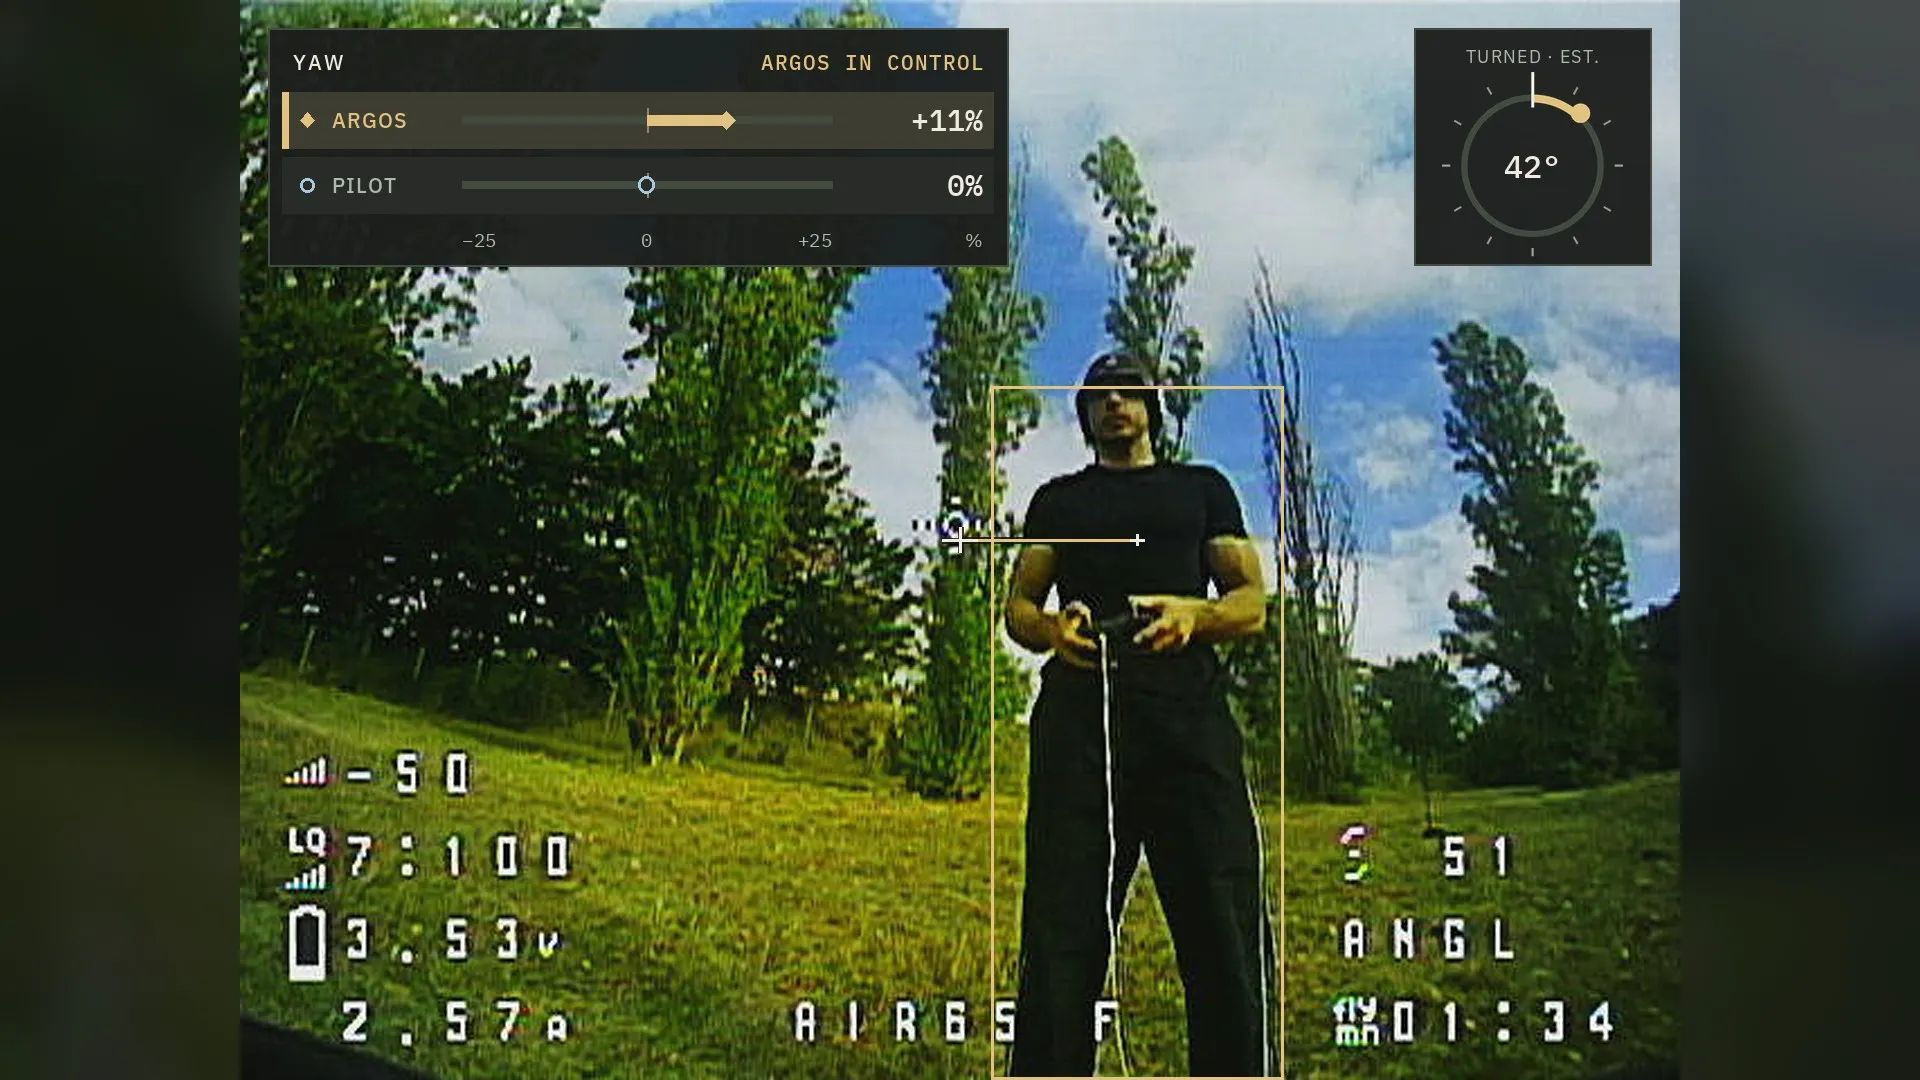
    argos successfully controlled the yaw to keep the subject centered while the pilot handled the rest. but distance control didn’t work.

  8. now

    Improving the CV model

    Image — no description provided.
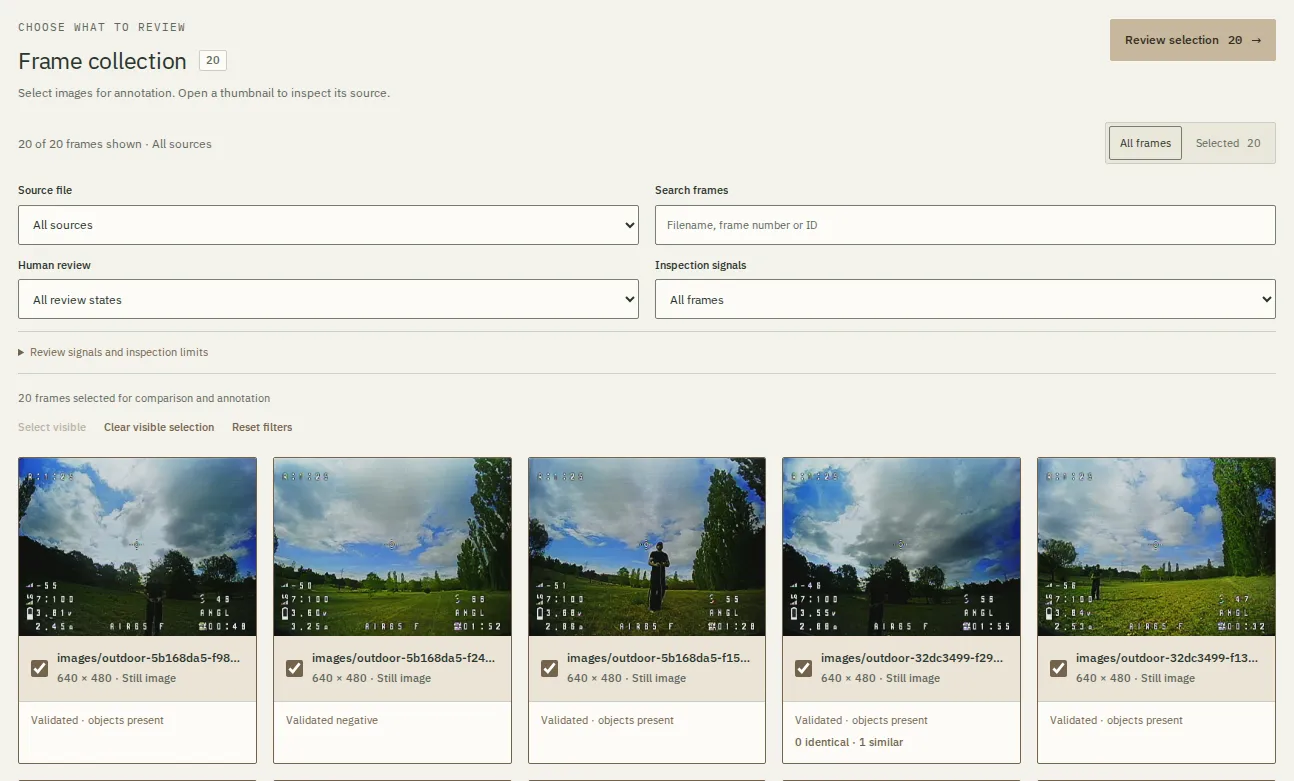
    preparing argos images in iris
    Image — no description provided.
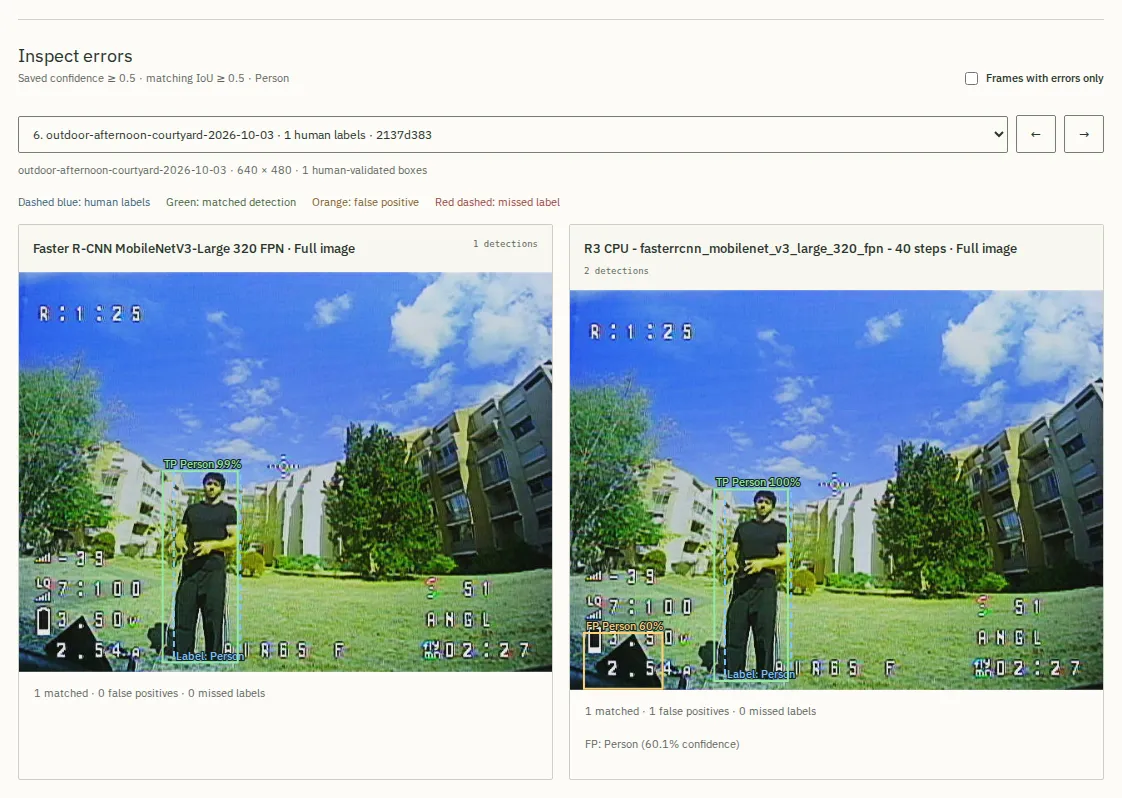
    comparing models in iris

    used iris to improve person detection. tested the new model on recordings of my previous flights before trying it outside again.